03 / ONGOING / ROBOTICS · MECHANISMS

STARX
2027X
EXOSKELETON

A two-year redesign of STARX's powered lower-body exoskeleton, focused on adjustability, lightweighting, direct-drive joints, and making the system fit a much broader range of pilots.

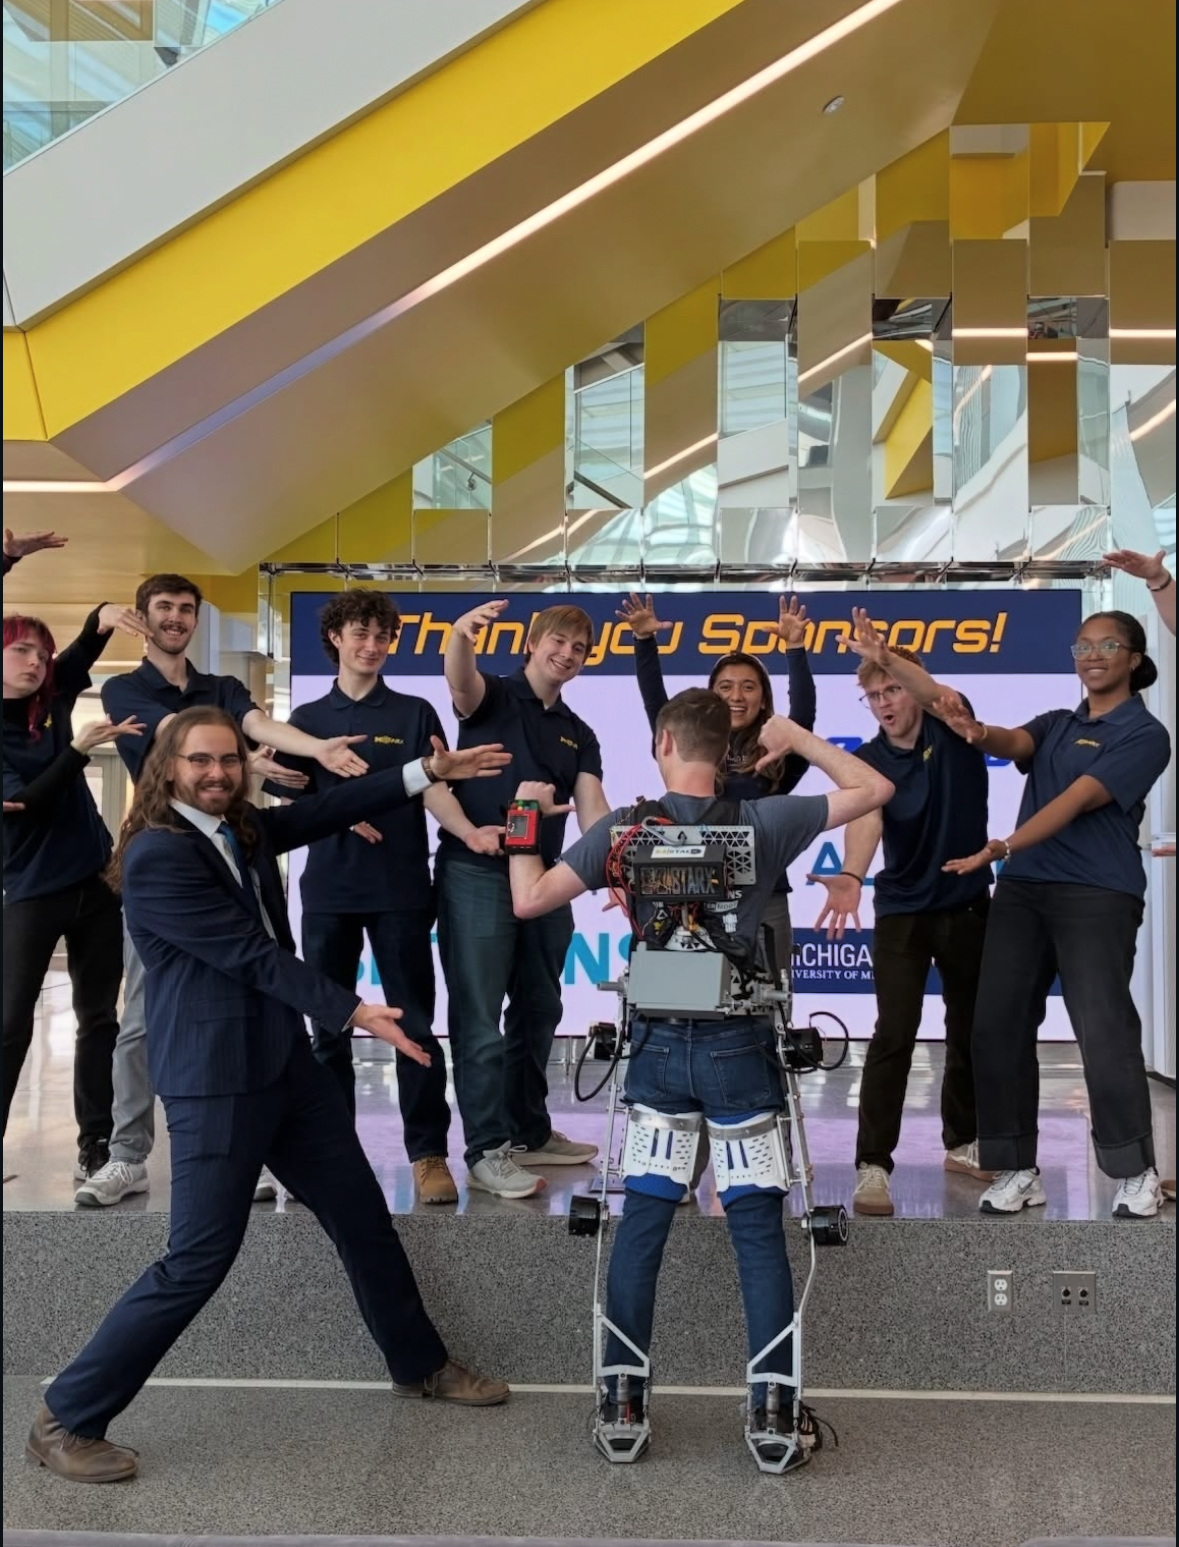
TEAM STARX — University of Michigan
ROLE 2027X Mechanical Co-Lead
EXOSKELETON EVE
SKILLS Mechanical Design,
CAD, Design Reviews,
Fabrication, Prototyping
01

STARTING WITH RALPH 2.0

I joined STARX as a freshman on the mechanical redesign team. One of my first major projects was redesigning the hip joint for the 2025 exoskeleton, RALPH 2.0.

The previous hip was bulky and restrictive, so I designed a more compact replacement. I then helped manufacture the design alongside other team members, and the finished hip was integrated into the final exoskeleton.

02

WHY 2027X?

During my sophomore year, I co-led a new team called 2027X. Historically, STARX tried to complete mechanical, electrical, and software development within a single academic year, which left each subteam with limited time to iterate.

2027X shifted the program toward a two-year design cycle: year one for mechanical design and fabrication, and year two for electrical integration and programming. That gave us time to rethink some of the exoskeleton's most fundamental design challenges instead of only making incremental changes.

03

DESIGNING EVE

My co-lead and I coordinated the mechanical design of the new exoskeleton, which we named EVE. We spent a long time in ideation and completed multiple design reviews with STARX upperclassmen, industry professionals, and professional engineers.

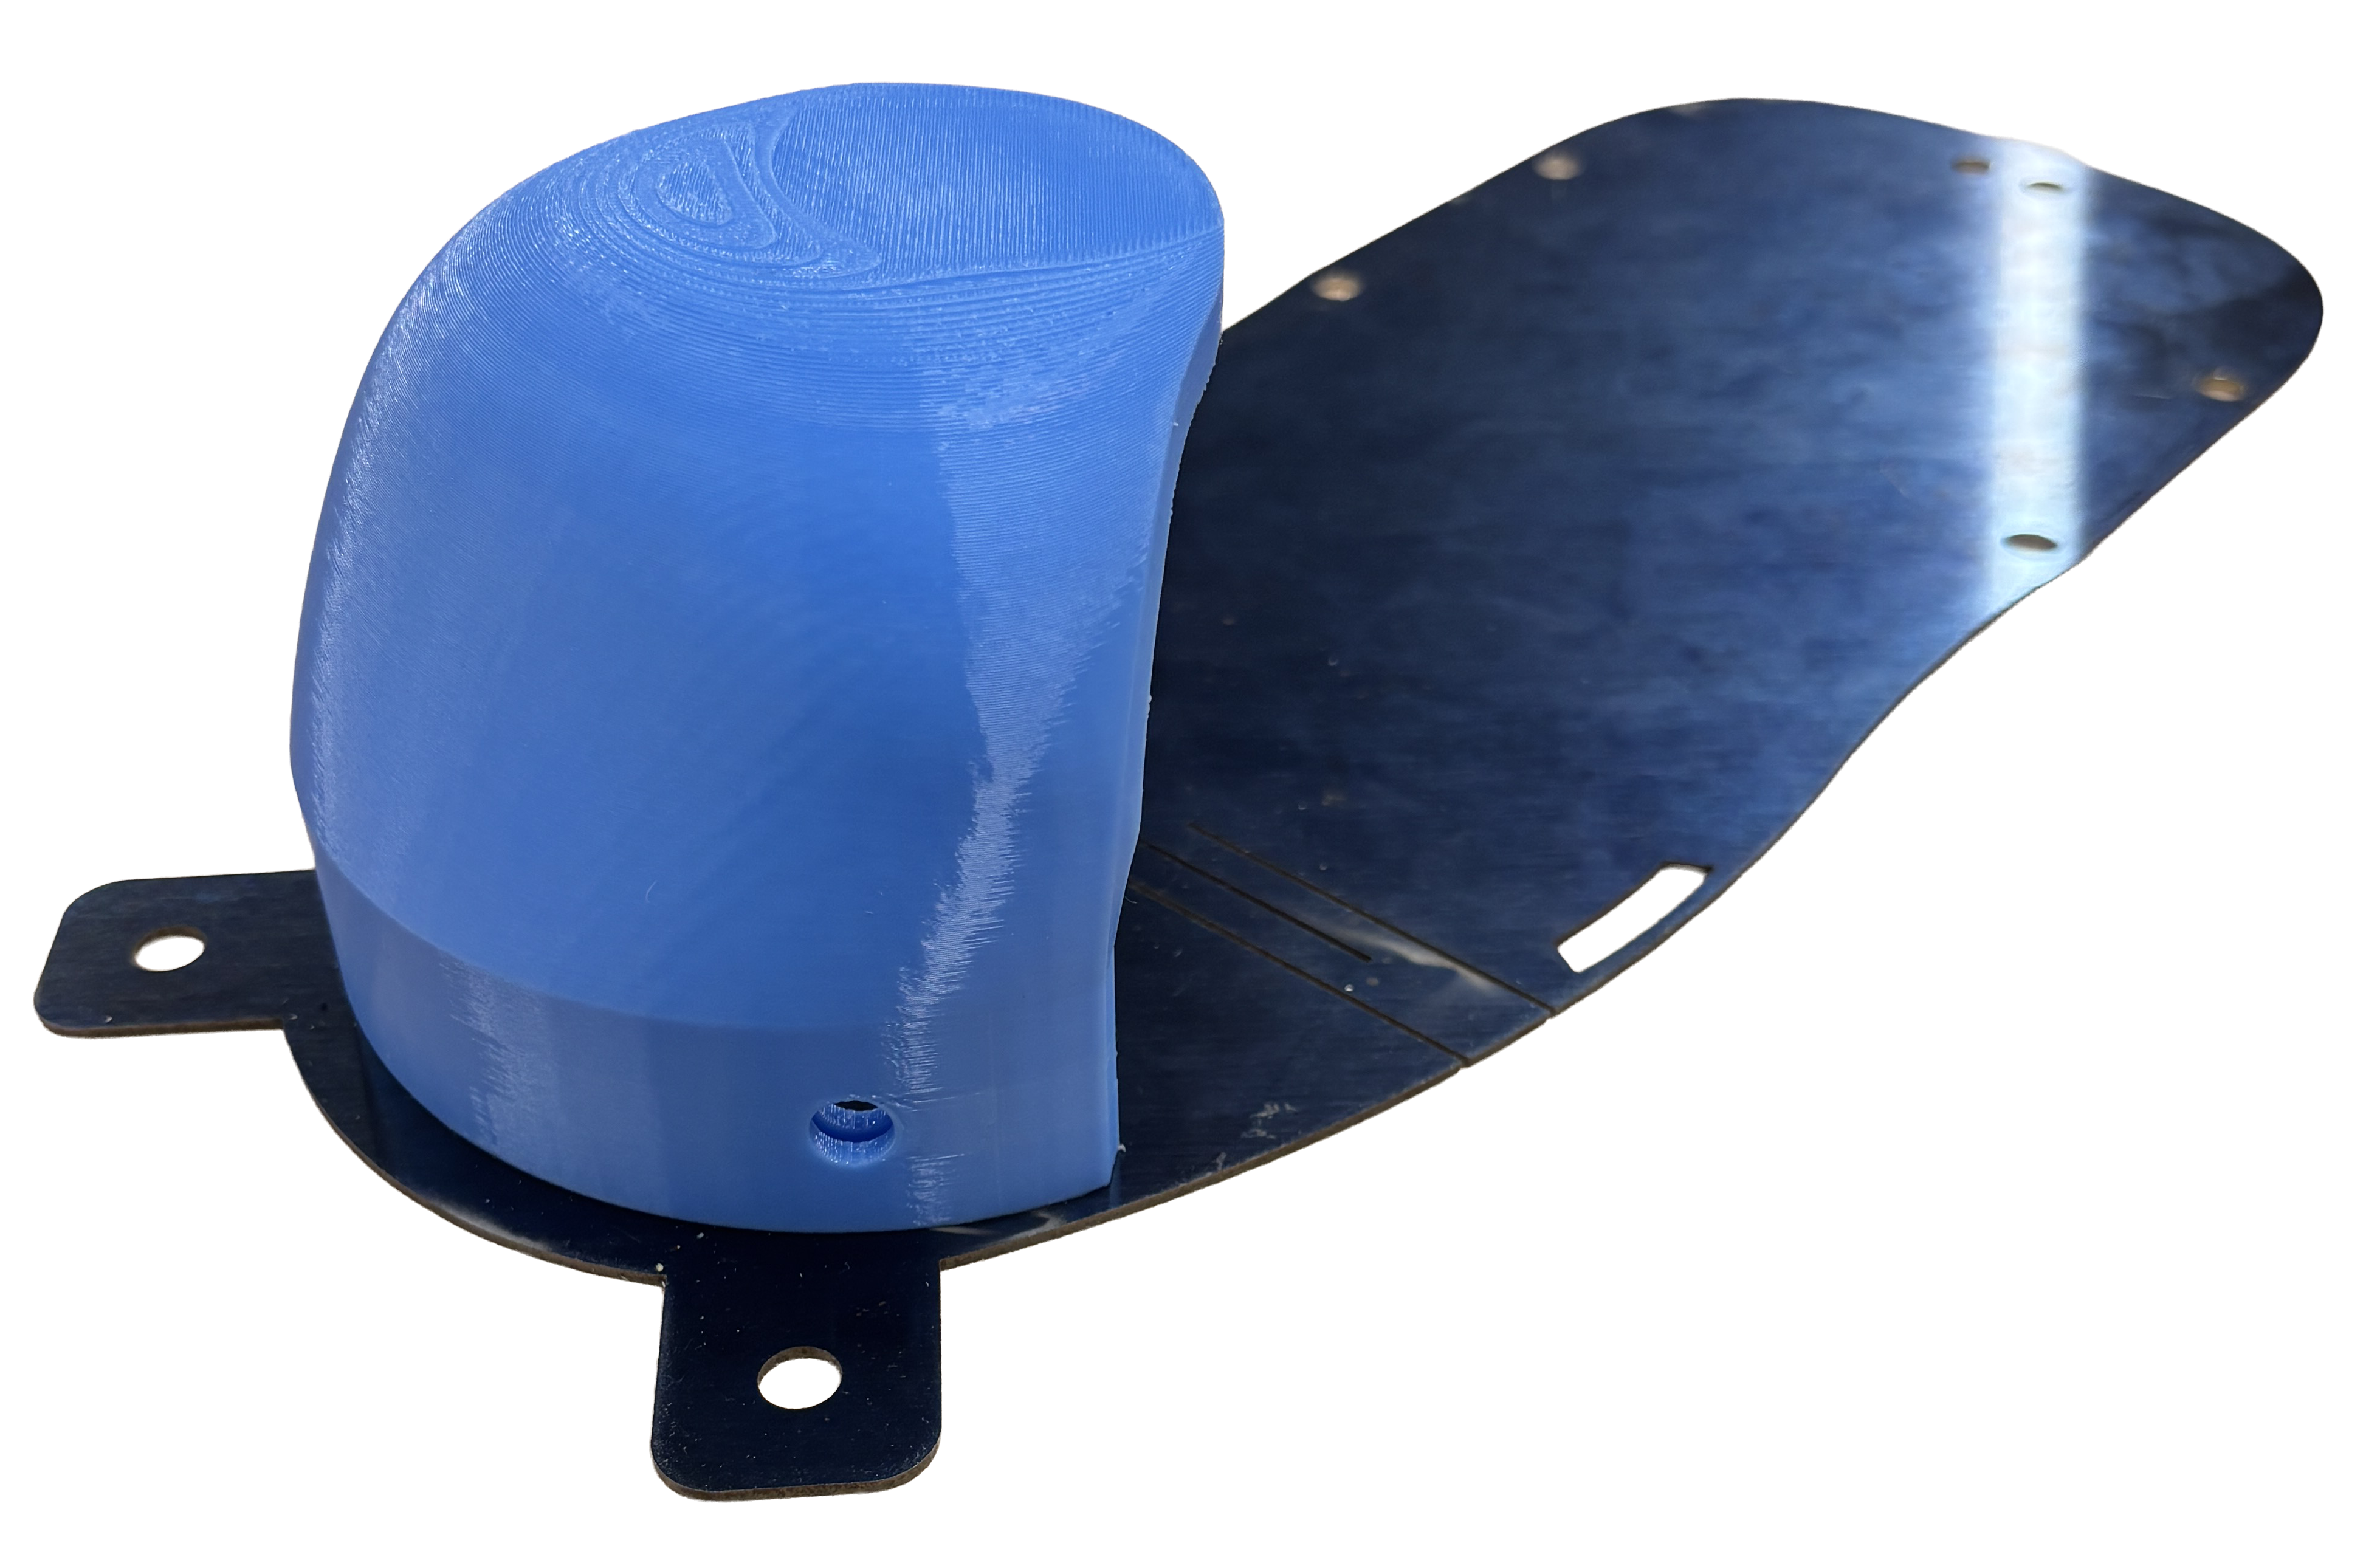
By the end of the academic year, we had begun manufacturing components including the ankle and adjustment segments. We are on track to complete mechanical manufacturing by the end of first semester this year.
04 / KEY DESIGN PRIORITIES ADJUSTABILITY · LIGHTWEIGHTING · DIRECT DRIVE
01

ADJUSTABILITY

Previous STARX exoskeletons were modeled around one pre-selected pilot. EVE was designed from the beginning to accommodate a much wider range of body dimensions and specifically improve comfort for female pilots, including greater attention to Q-angle.

02

MULTI-AXIS FIT

Dovetail sliders move the hips inward and outward, spring steel hip plates provide radial adjustment, and toothed adjustment sections change the effective length of both thigh and calf segments.

03

FLEXIBLE BRACING

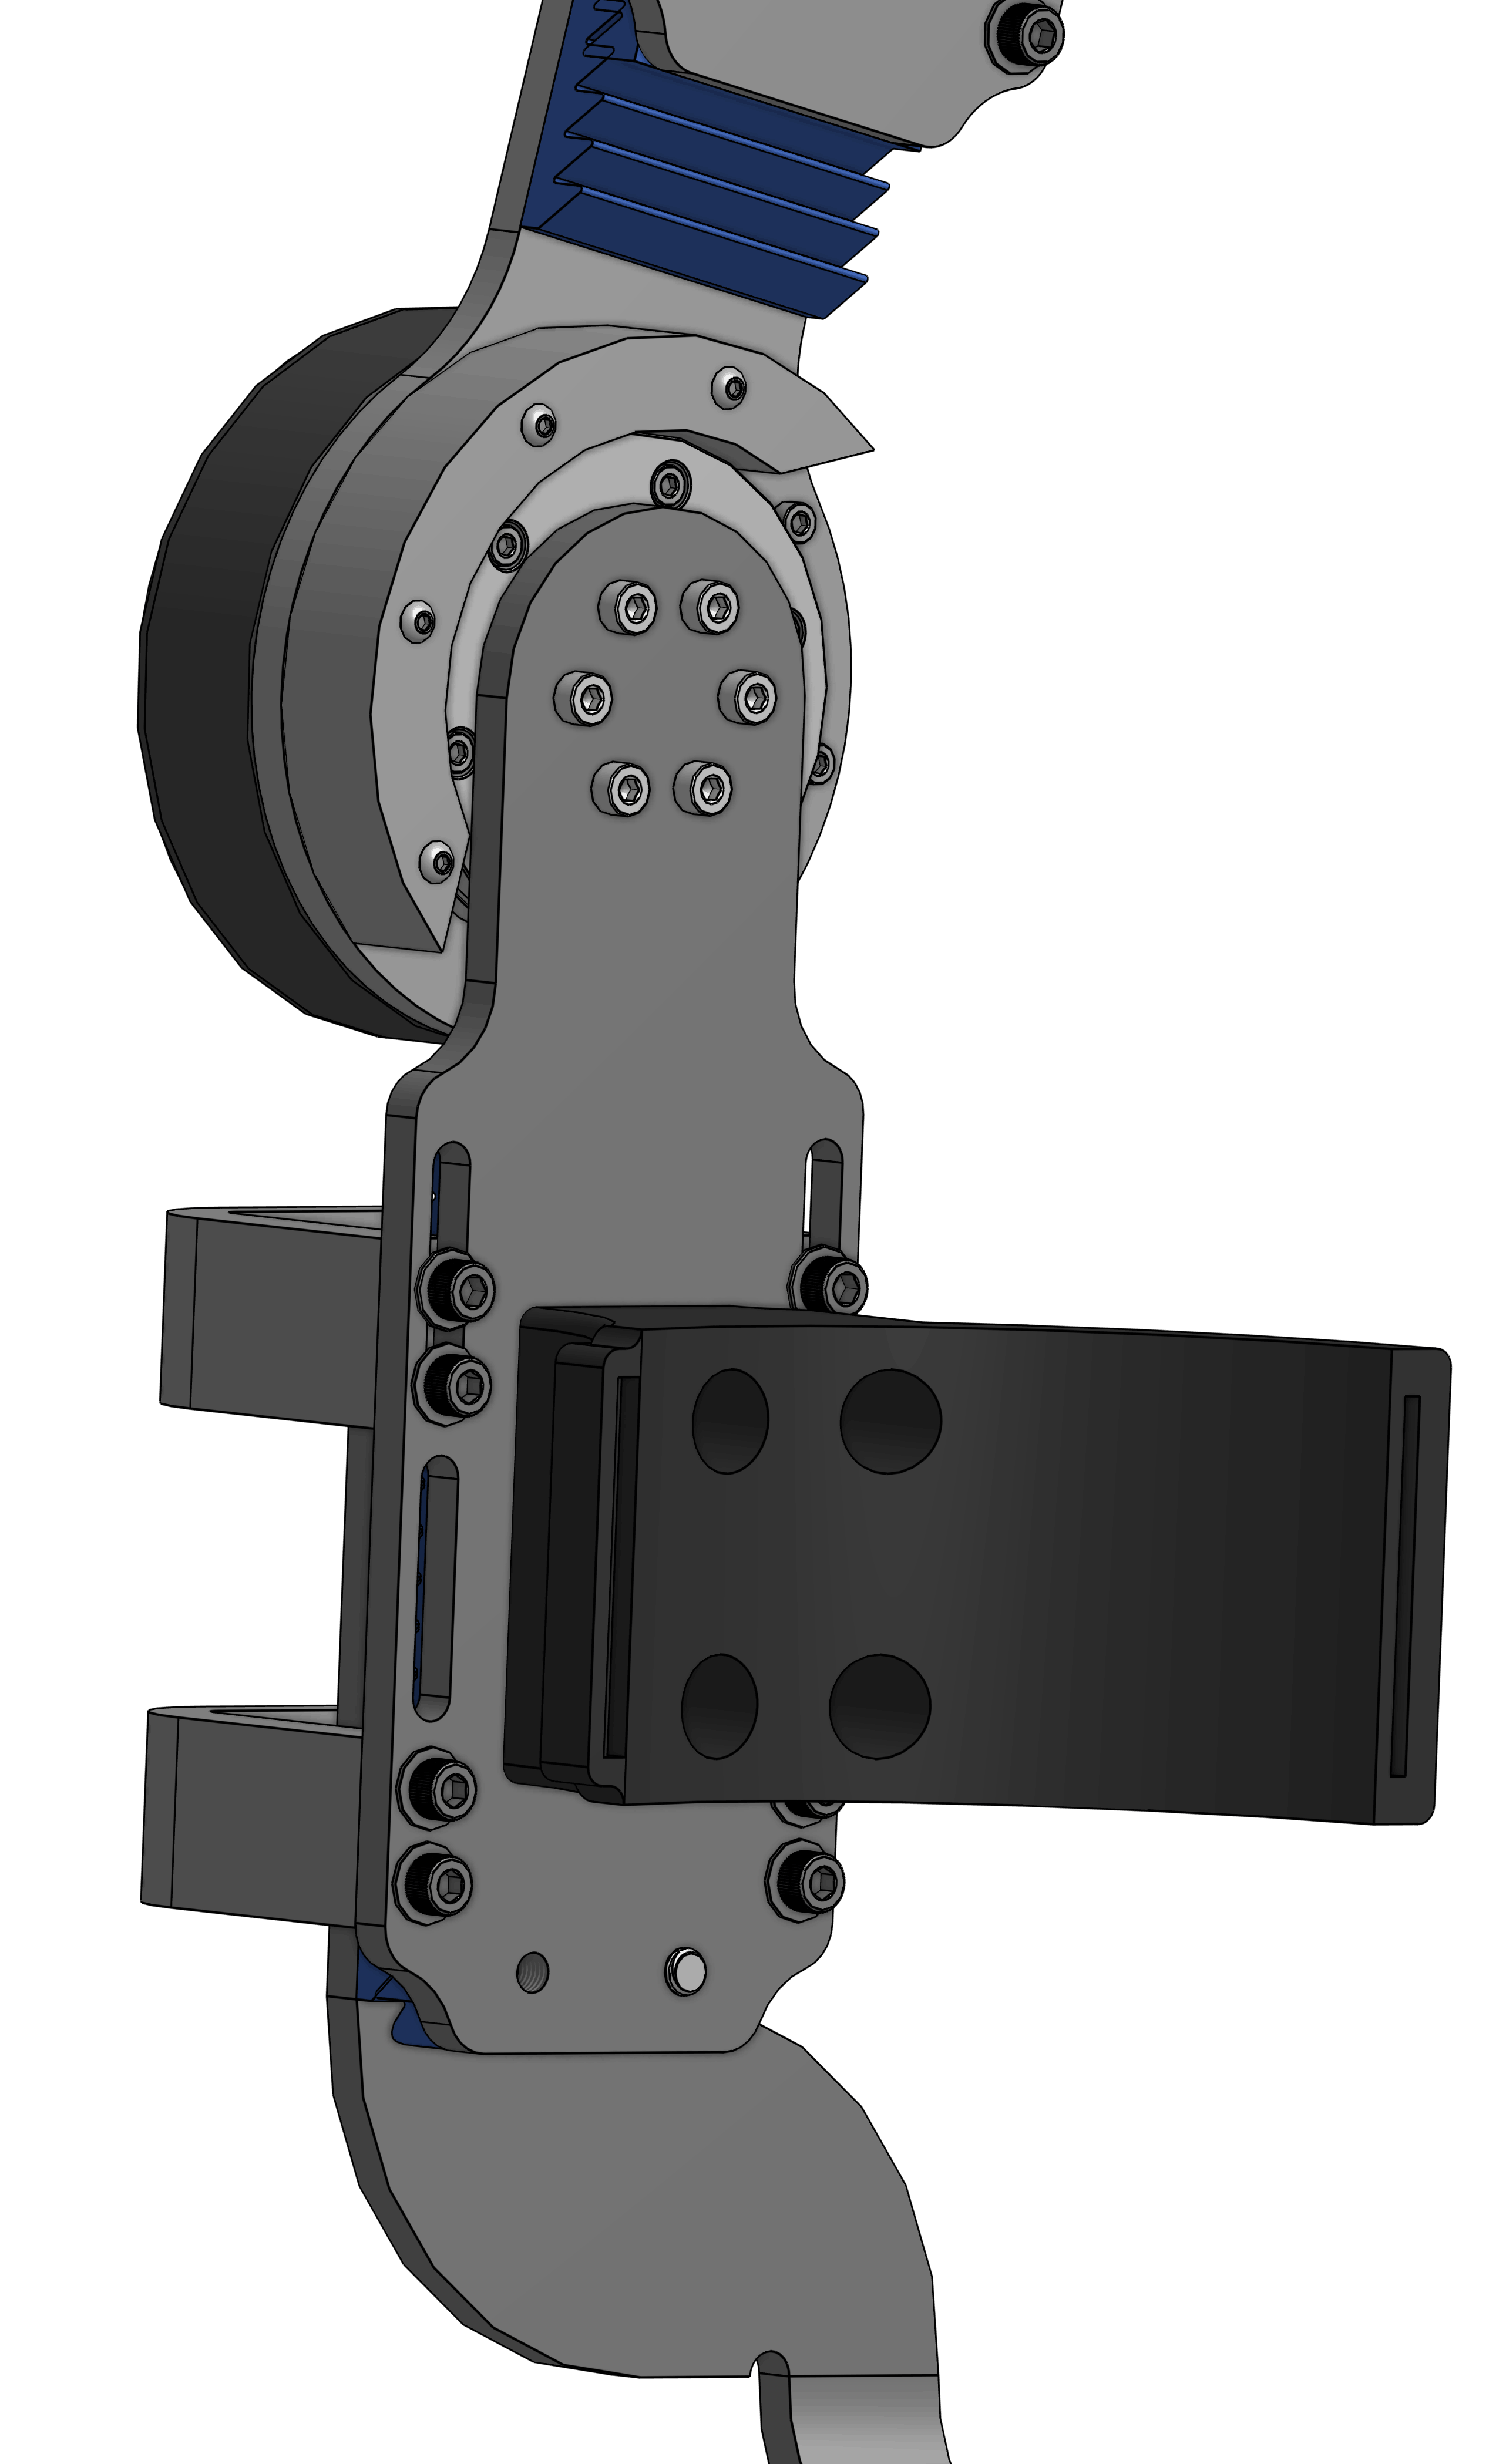
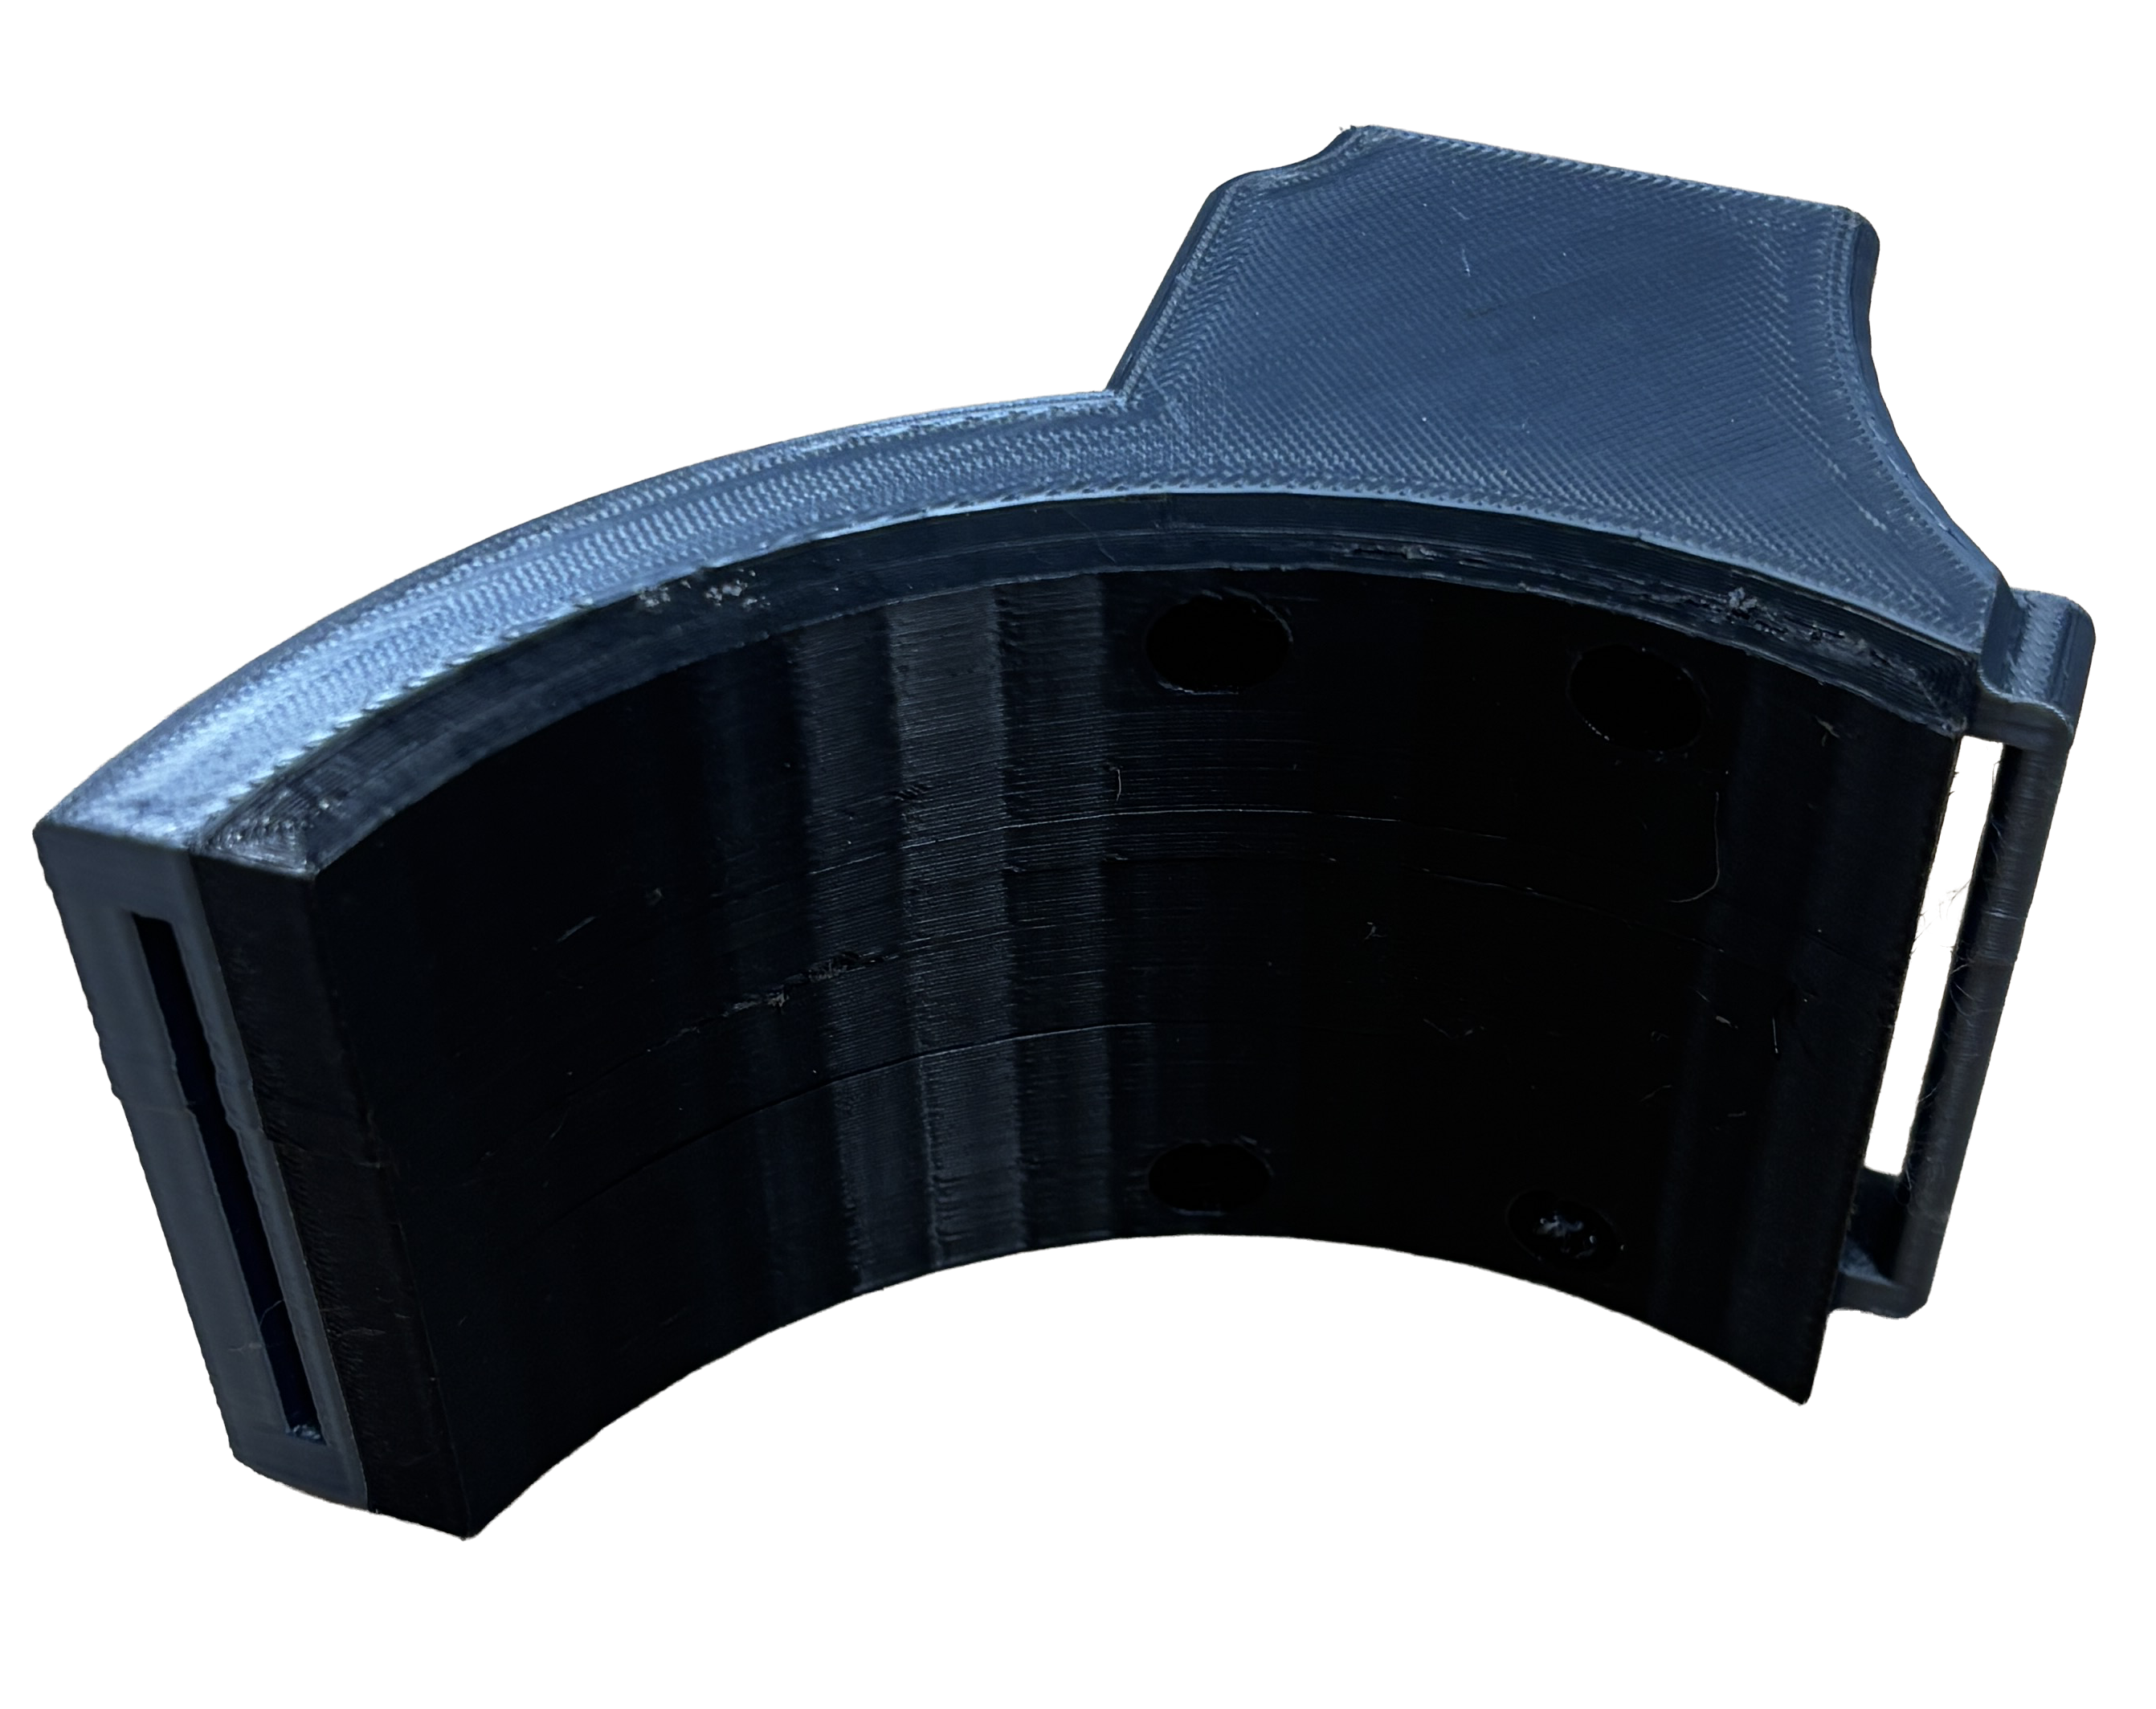
Curved leg braces are 3D printed from flexible filament, allowing them to conform more securely to users with different leg sizes while maintaining a consistent attachment point to the exoskeleton.

04

DIRECT DRIVE

We replaced the previous chain-driven transmission with motors mounted directly at the joints. That simplified the drivetrain, but created new bearing and load-path challenges to prevent significant stress from reaching the motor shaft and housing.

05 / DESIGN DETAILS CAD + FABRICATION
Back corner CAD view showing the EVE hip adjustment mechanism
HIP ADJUSTABILITY / DOVETAIL + SPRING STEEL SYSTEM
Inner knee CAD view showing flexible brace and motor hard stop
INNER KNEE / FLEXIBLE BRACE + MOTOR HARD STOP
Flat CAD view focused on EVE leg adjustment section
LEG ADJUSTMENT / TOOTHED LENGTH CONTROL