01
STARTING WITH RALPH 2.0
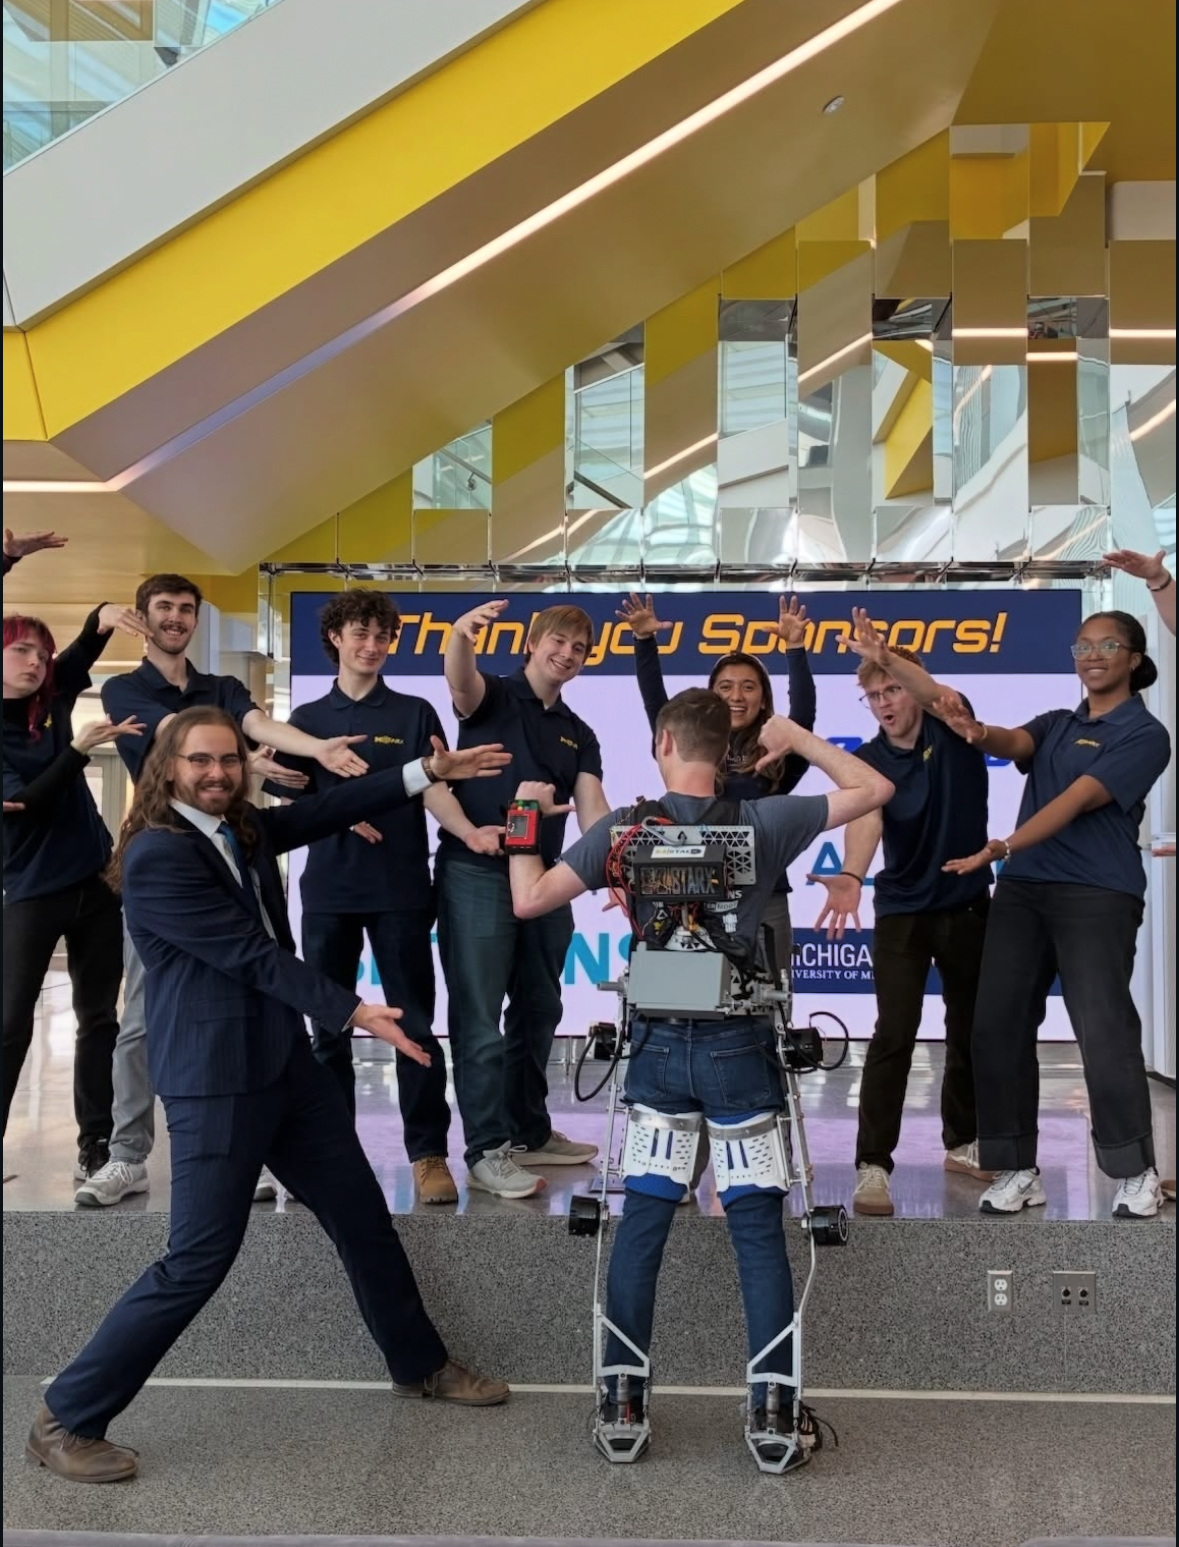
I joined STARX as a freshman on the mechanical redesign team.
One of my first major projects was redesigning the hip joint
for the 2025 exoskeleton, RALPH 2.0.
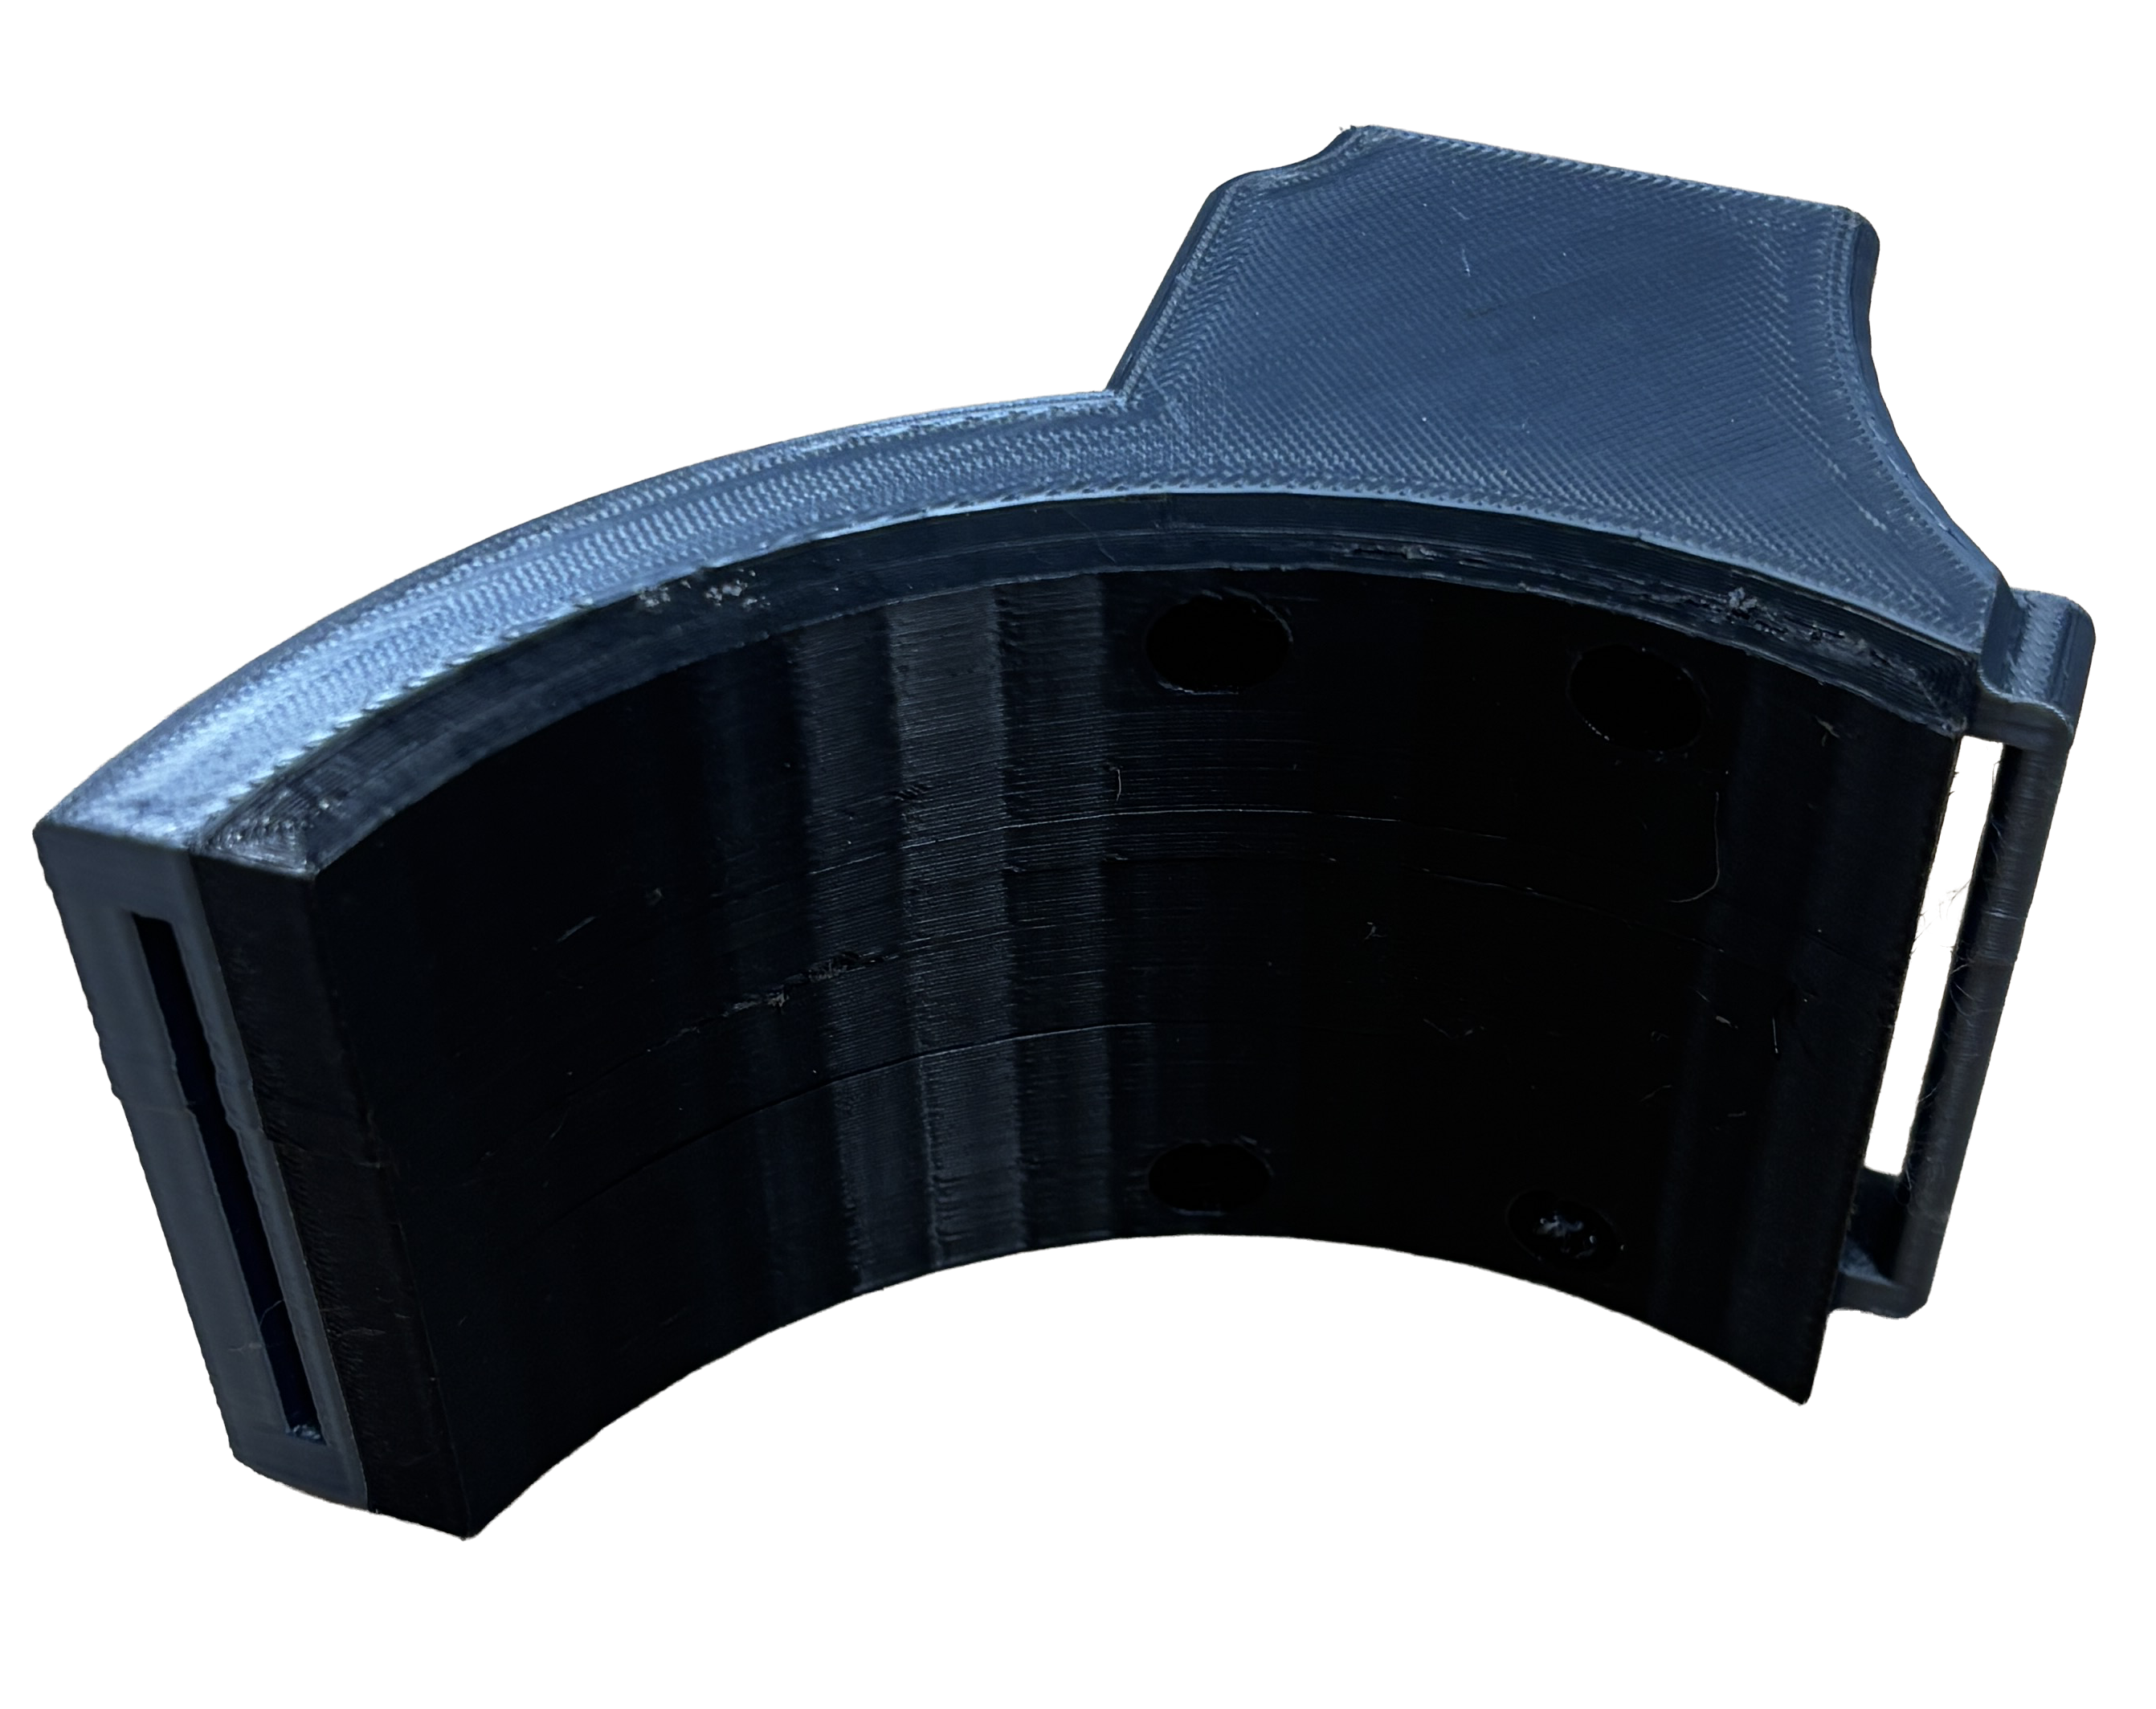
The previous hip was bulky and restrictive, so I designed a
more compact replacement. I then helped manufacture the design
alongside other team members, and the finished hip was integrated
into the final exoskeleton.
02
WHY 2027X?
During my sophomore year, I co-led a new team called 2027X.
Historically, STARX tried to complete mechanical, electrical,
and software development within a single academic year, which
left each subteam with limited time to iterate.
2027X shifted the program toward a two-year design cycle:
year one for mechanical design and fabrication, and year two
for electrical integration and programming. That gave us time
to rethink some of the exoskeleton's most fundamental design
challenges instead of only making incremental changes.
03
DESIGNING EVE
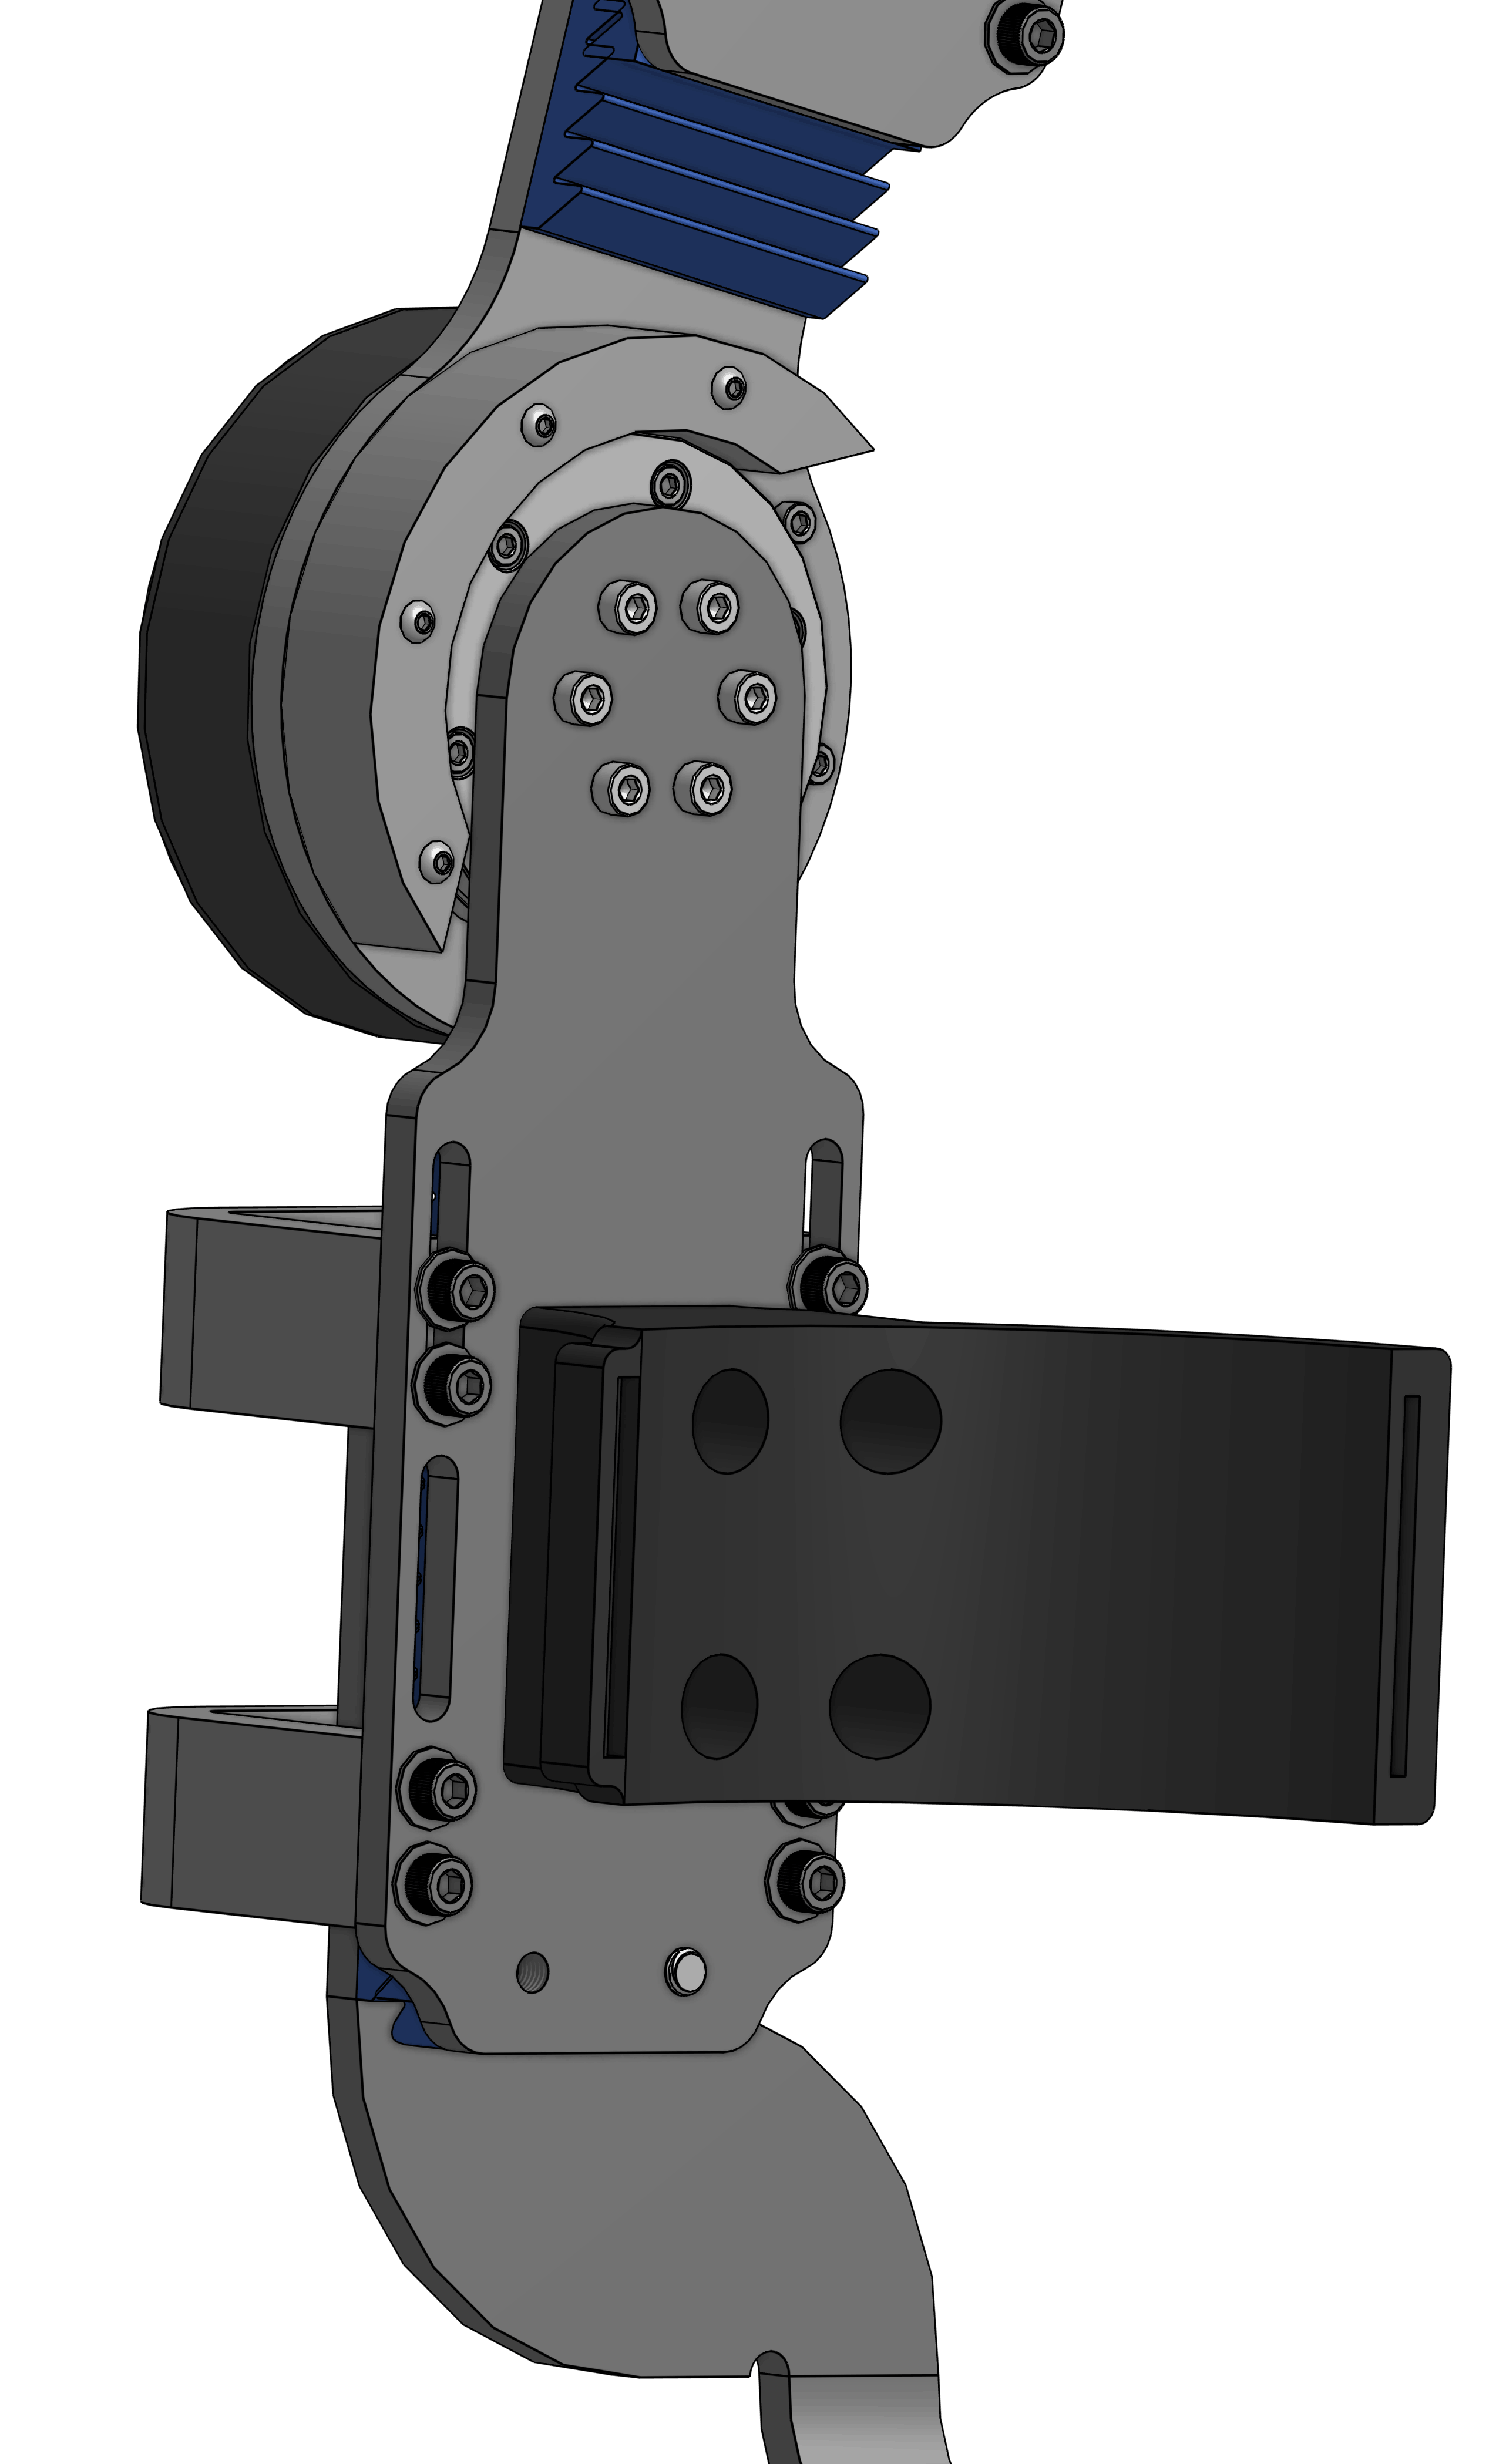
My co-lead and I coordinated the mechanical design of the new
exoskeleton, which we named EVE. We spent a long time in
ideation and completed multiple design reviews with STARX
upperclassmen, industry professionals, and professional engineers.
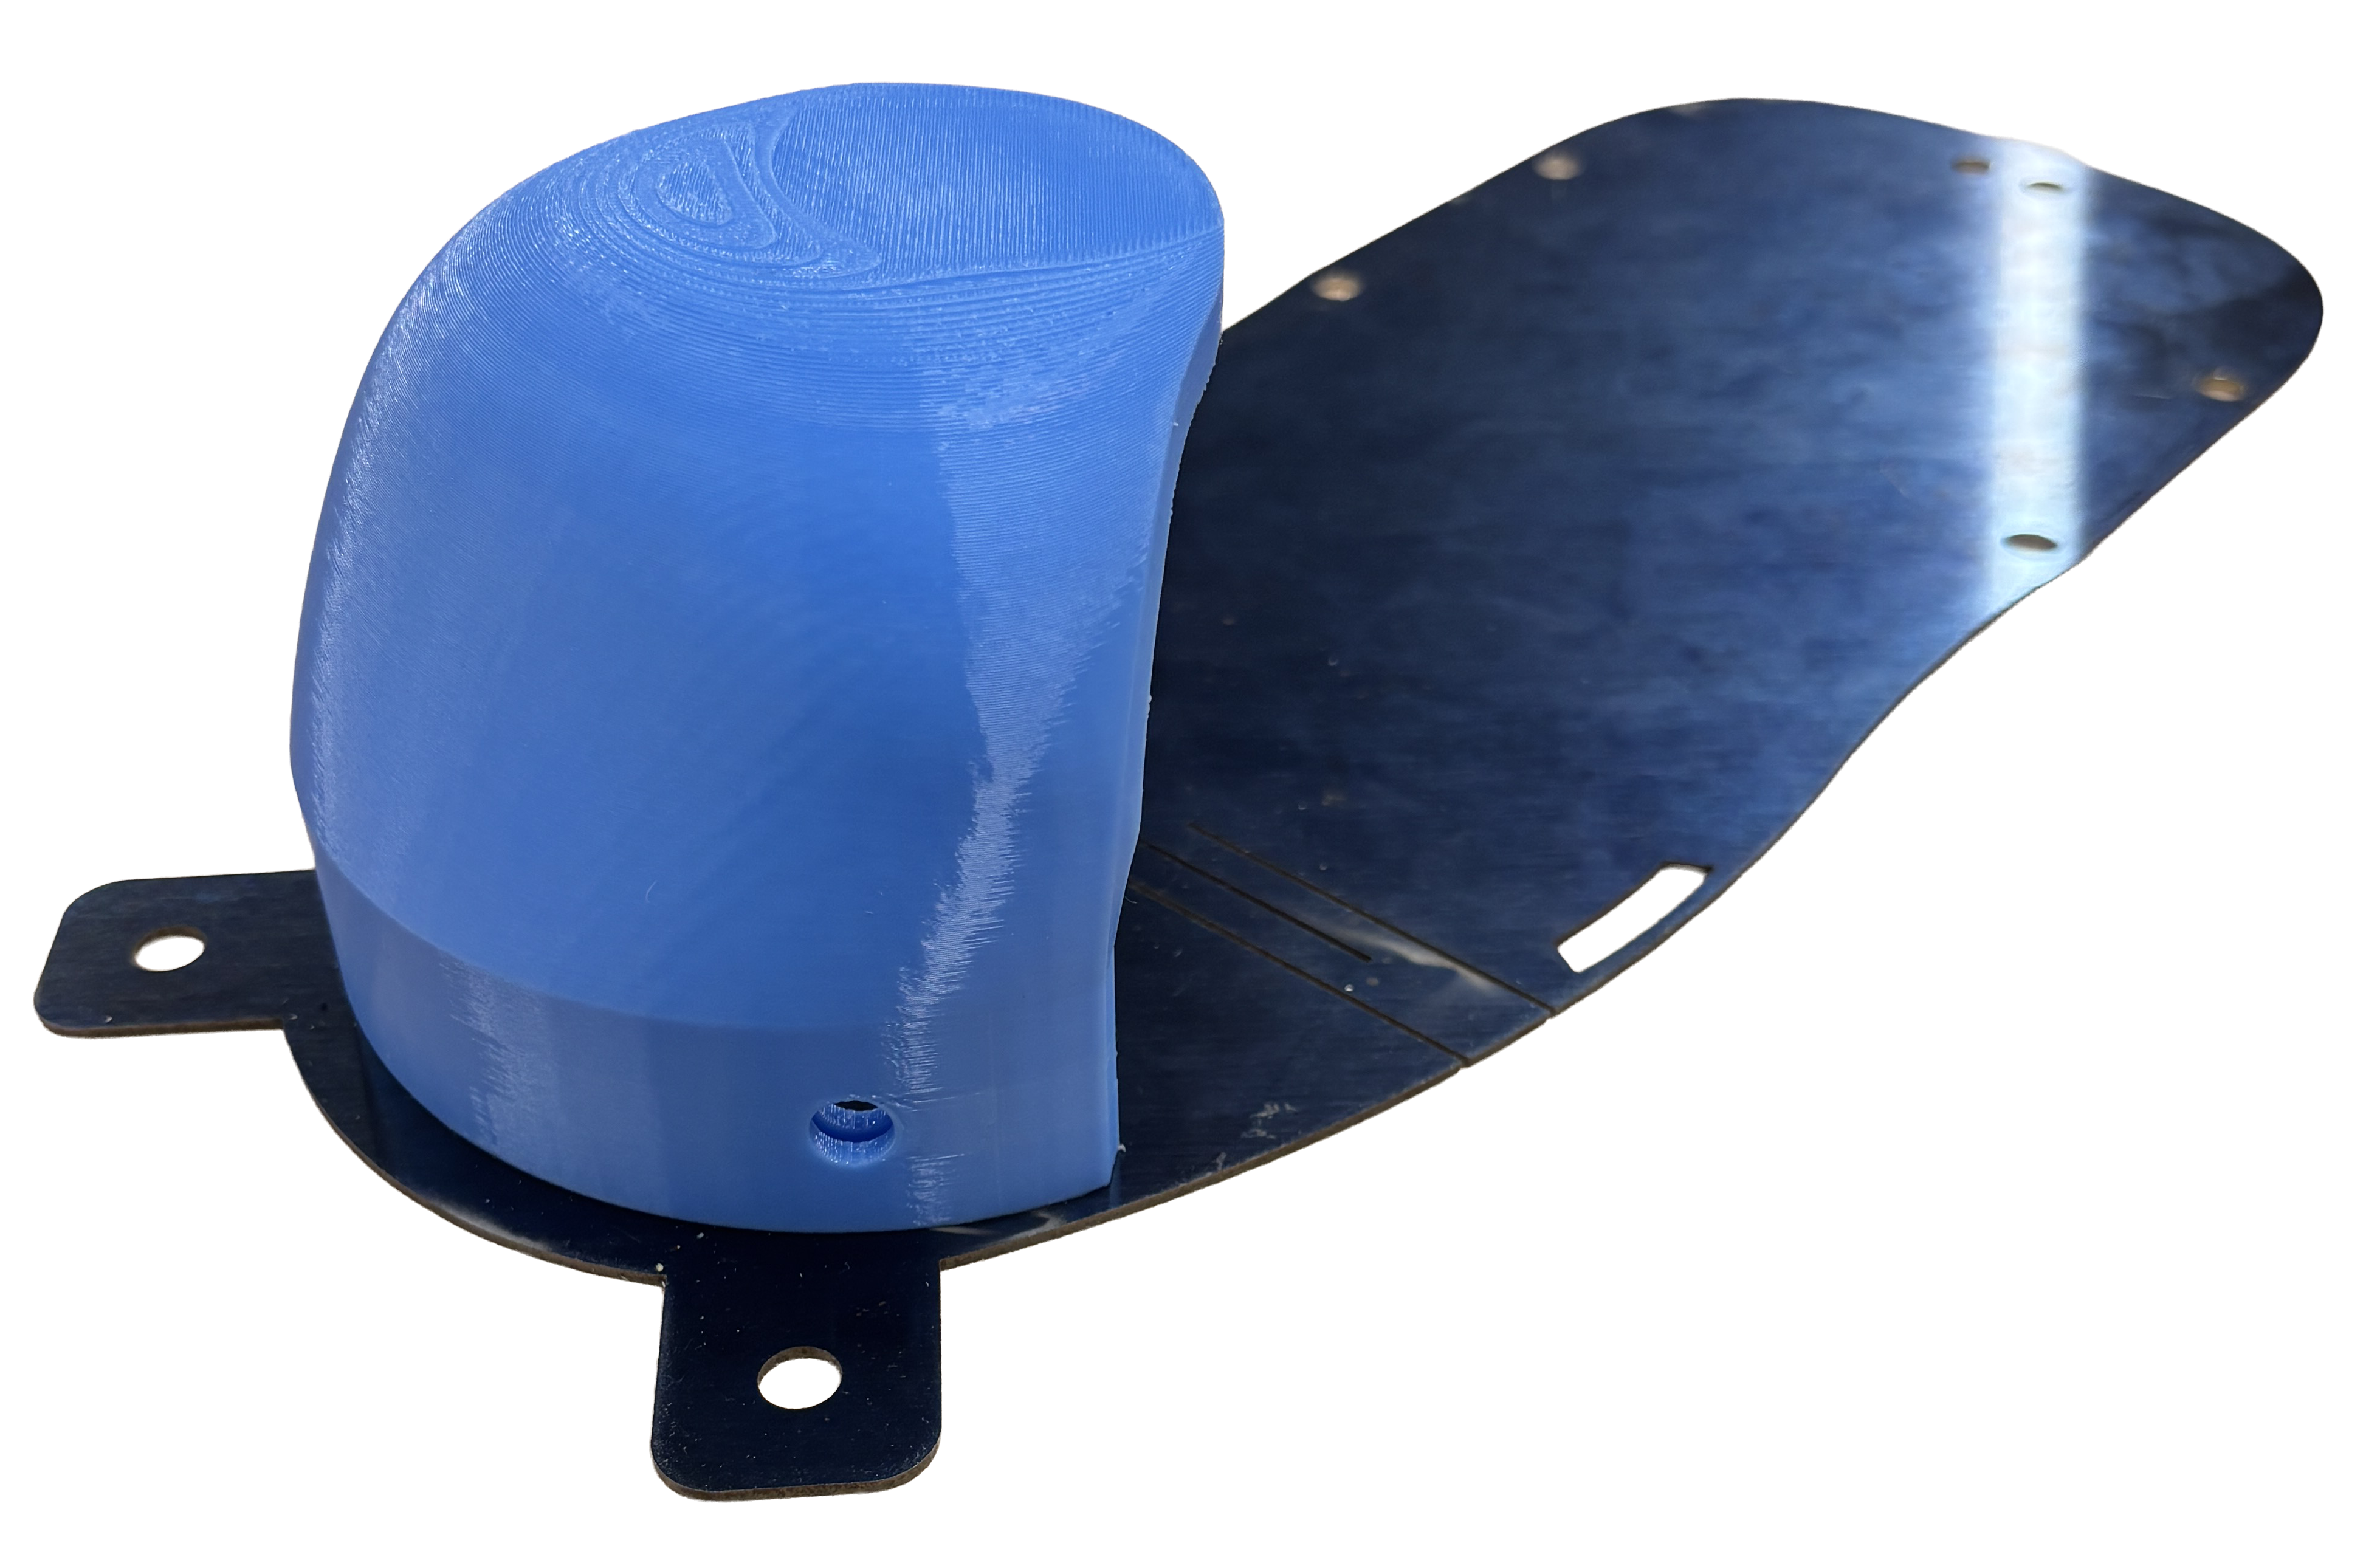
By the end of the academic year, we had begun manufacturing
components including the ankle and adjustment segments. We are
on track to complete mechanical manufacturing by the end of
first semester this year.