01
NEW TO DESIGN-INTEGRATION
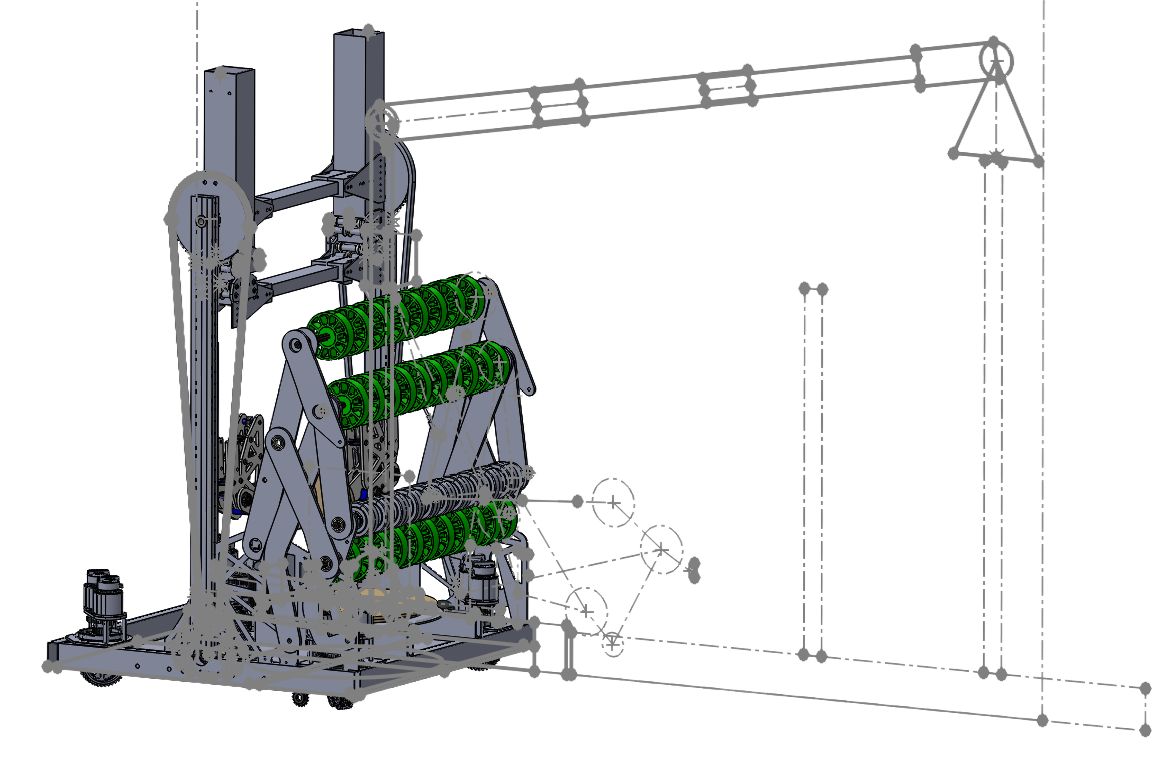
This was my junior year and my first season on Design-Integration, the subteam
responsible for CAD and design work for the mechanical team. I had just earned
my CSWA certification and was eager to use SolidWorks on a full robot.
The team had also just gone through a major leadership restructuring, and DI
was extremely disorganized. I was assigned ownership of the mechanism that
would collect and outtake cones and inflatable cubes.
02
THE GRAVITY CLAW IDEA
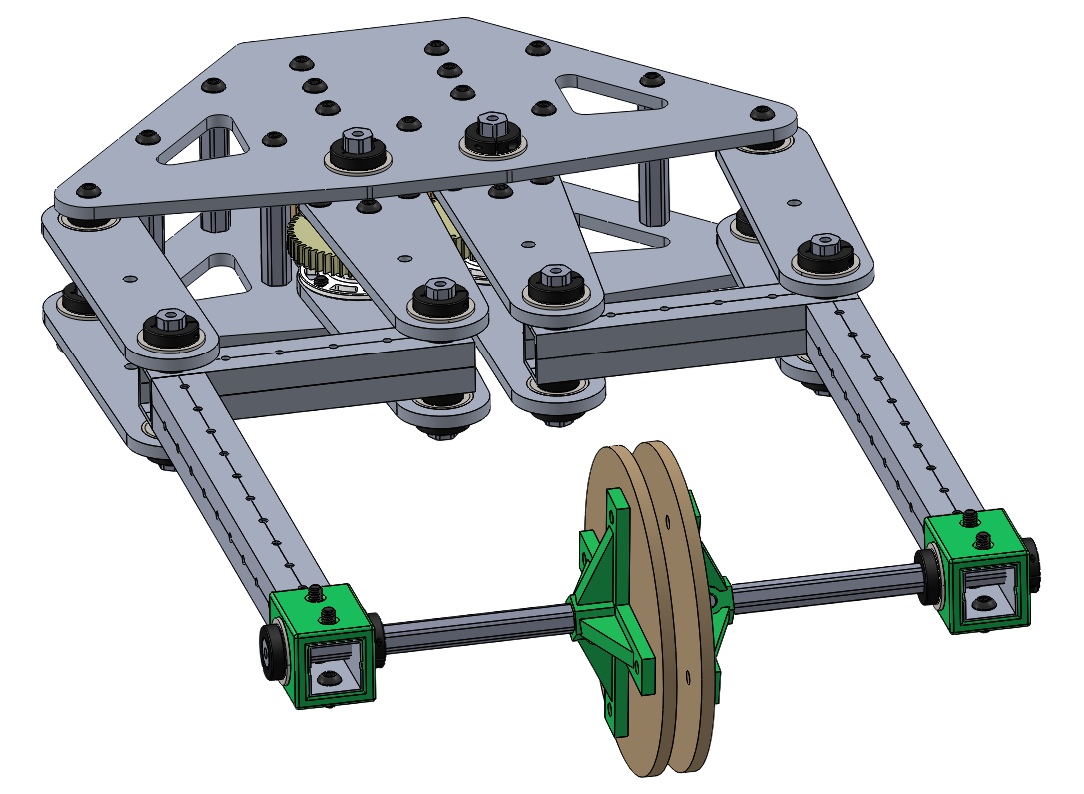
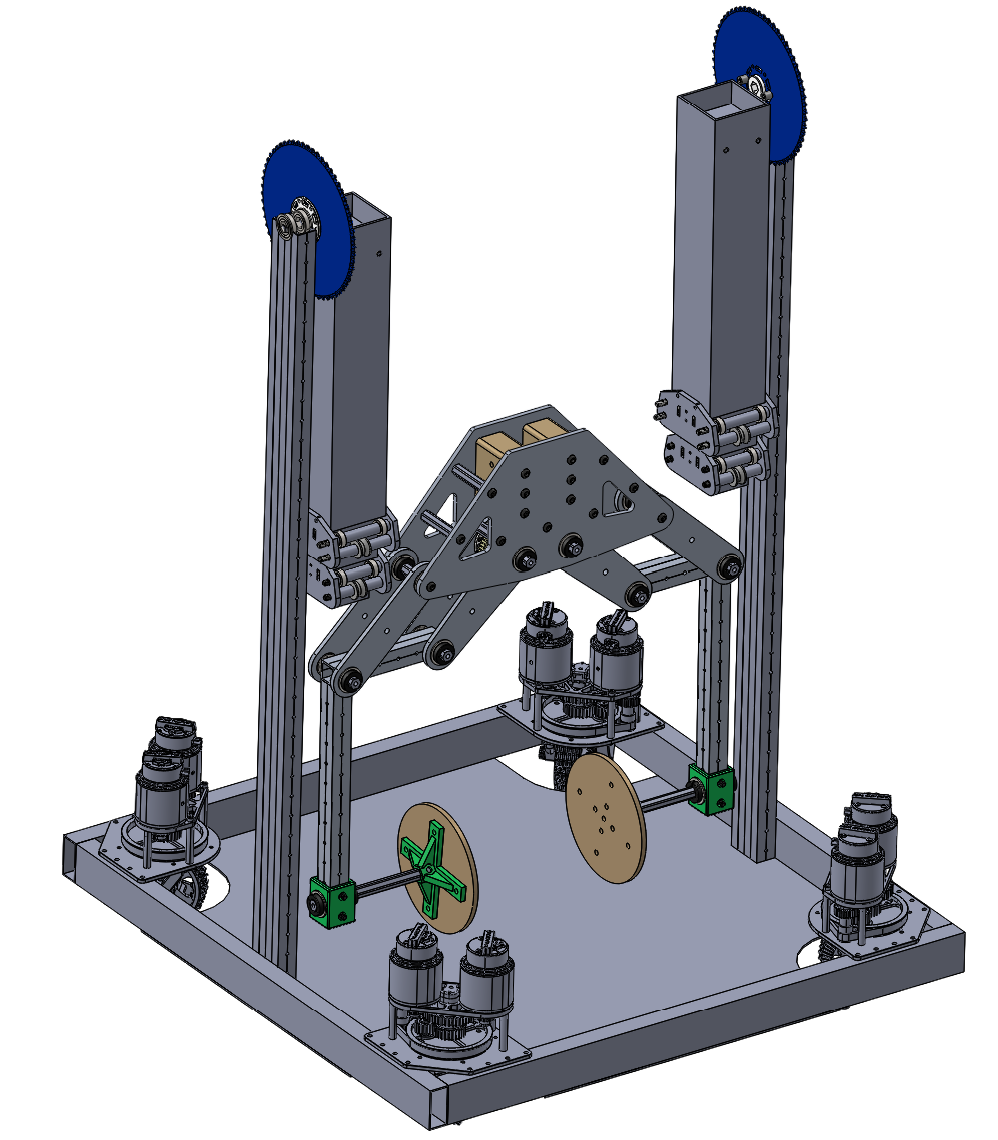
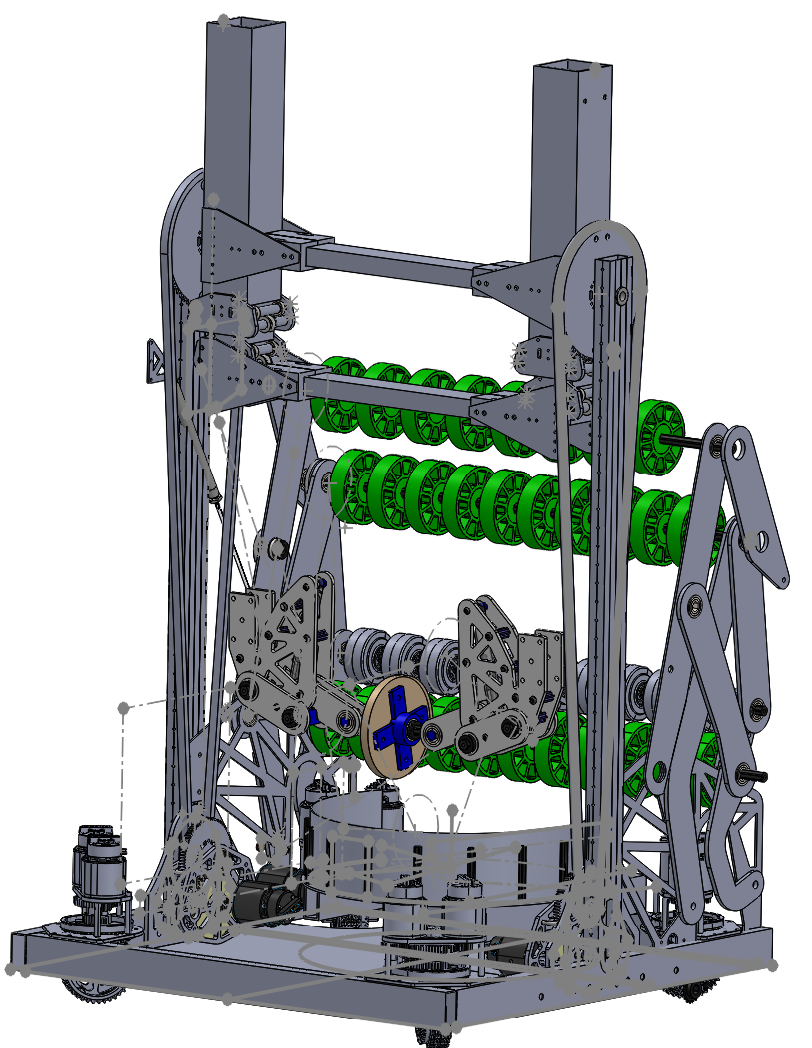
After a design discussion that was far too short, we settled on a claw.
My concept used freely rotating claw pads so a cone could automatically rotate
with its heavier base downward before being deposited.
That gravity-driven self-orientation is where the mechanism got its name:
the Gravity Claw.
03
ITERATION UNDER PRESSURE
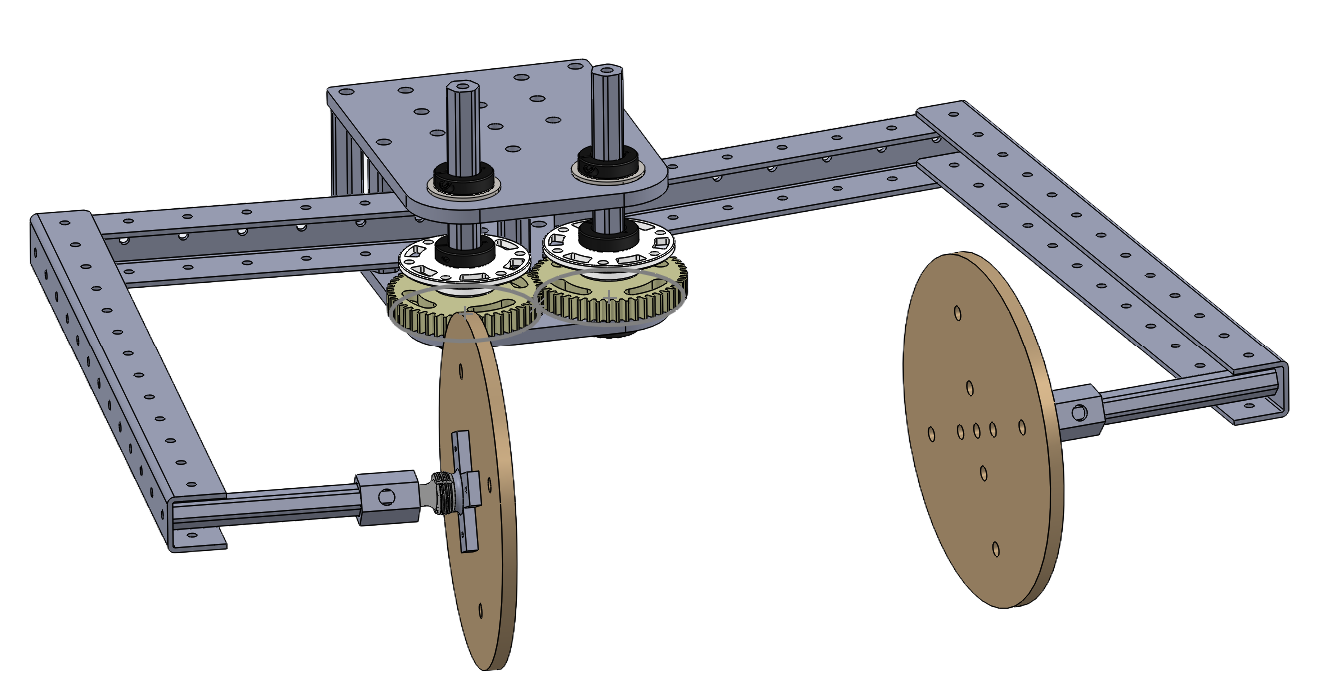
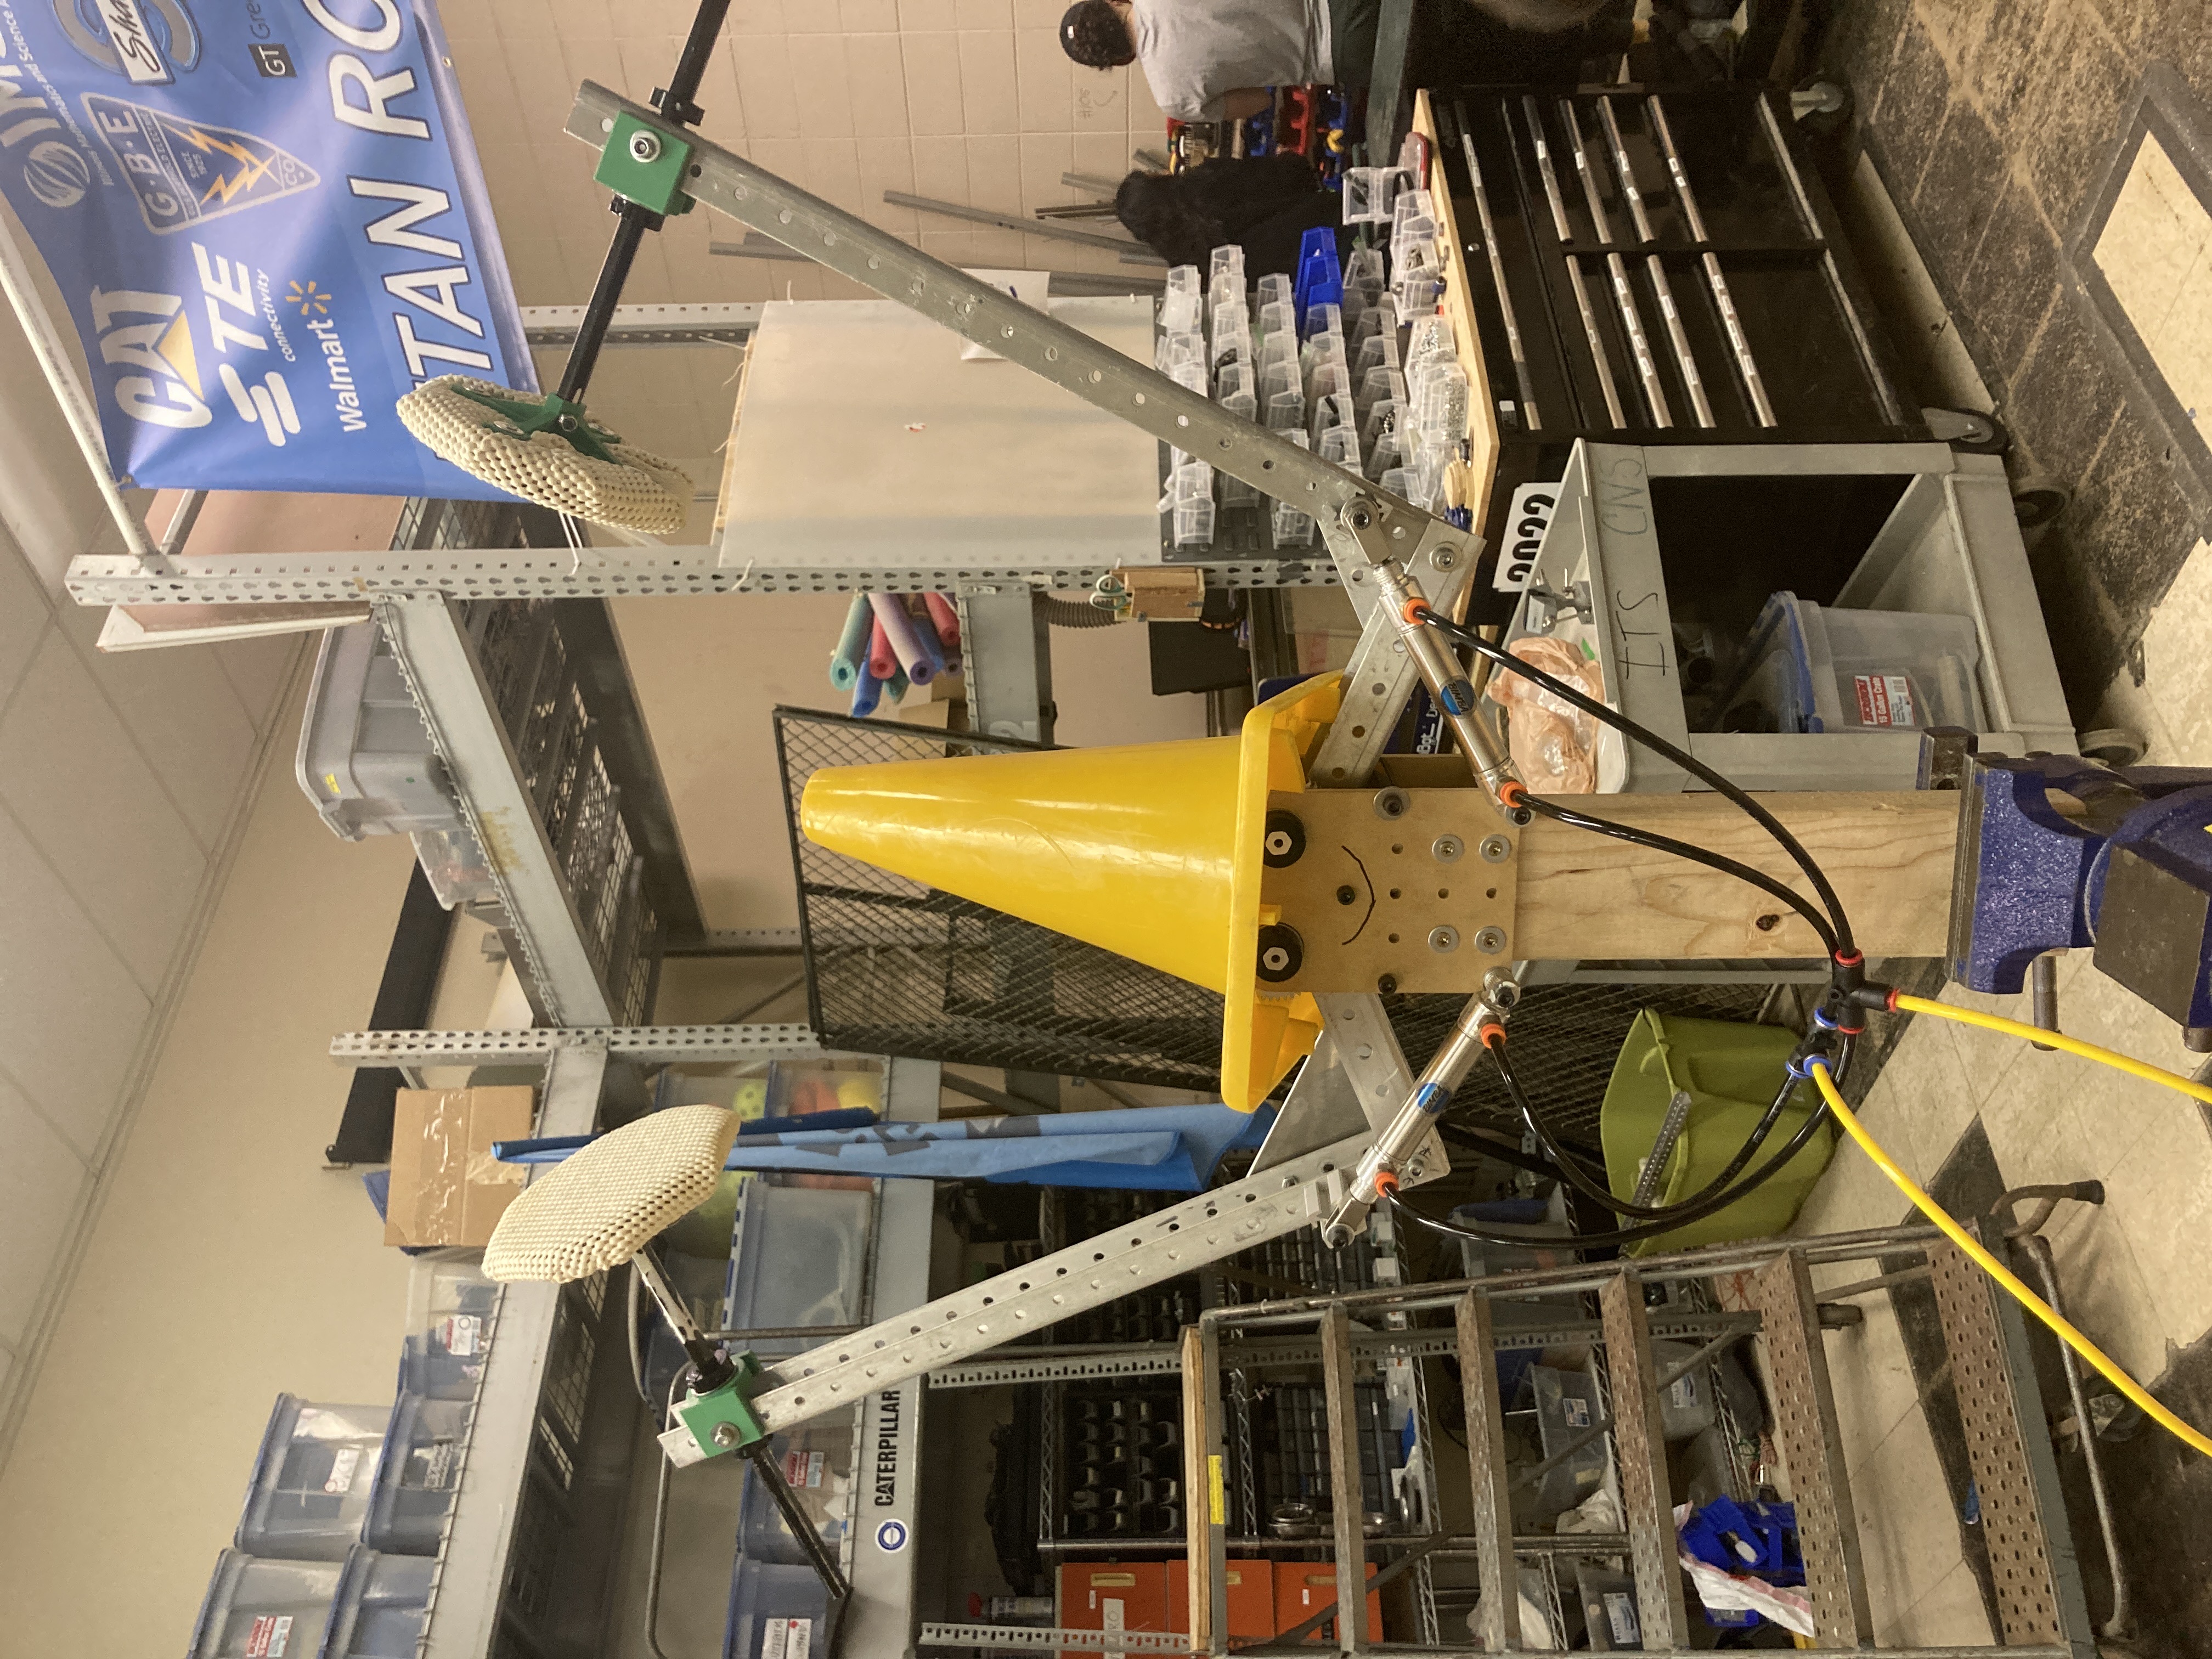
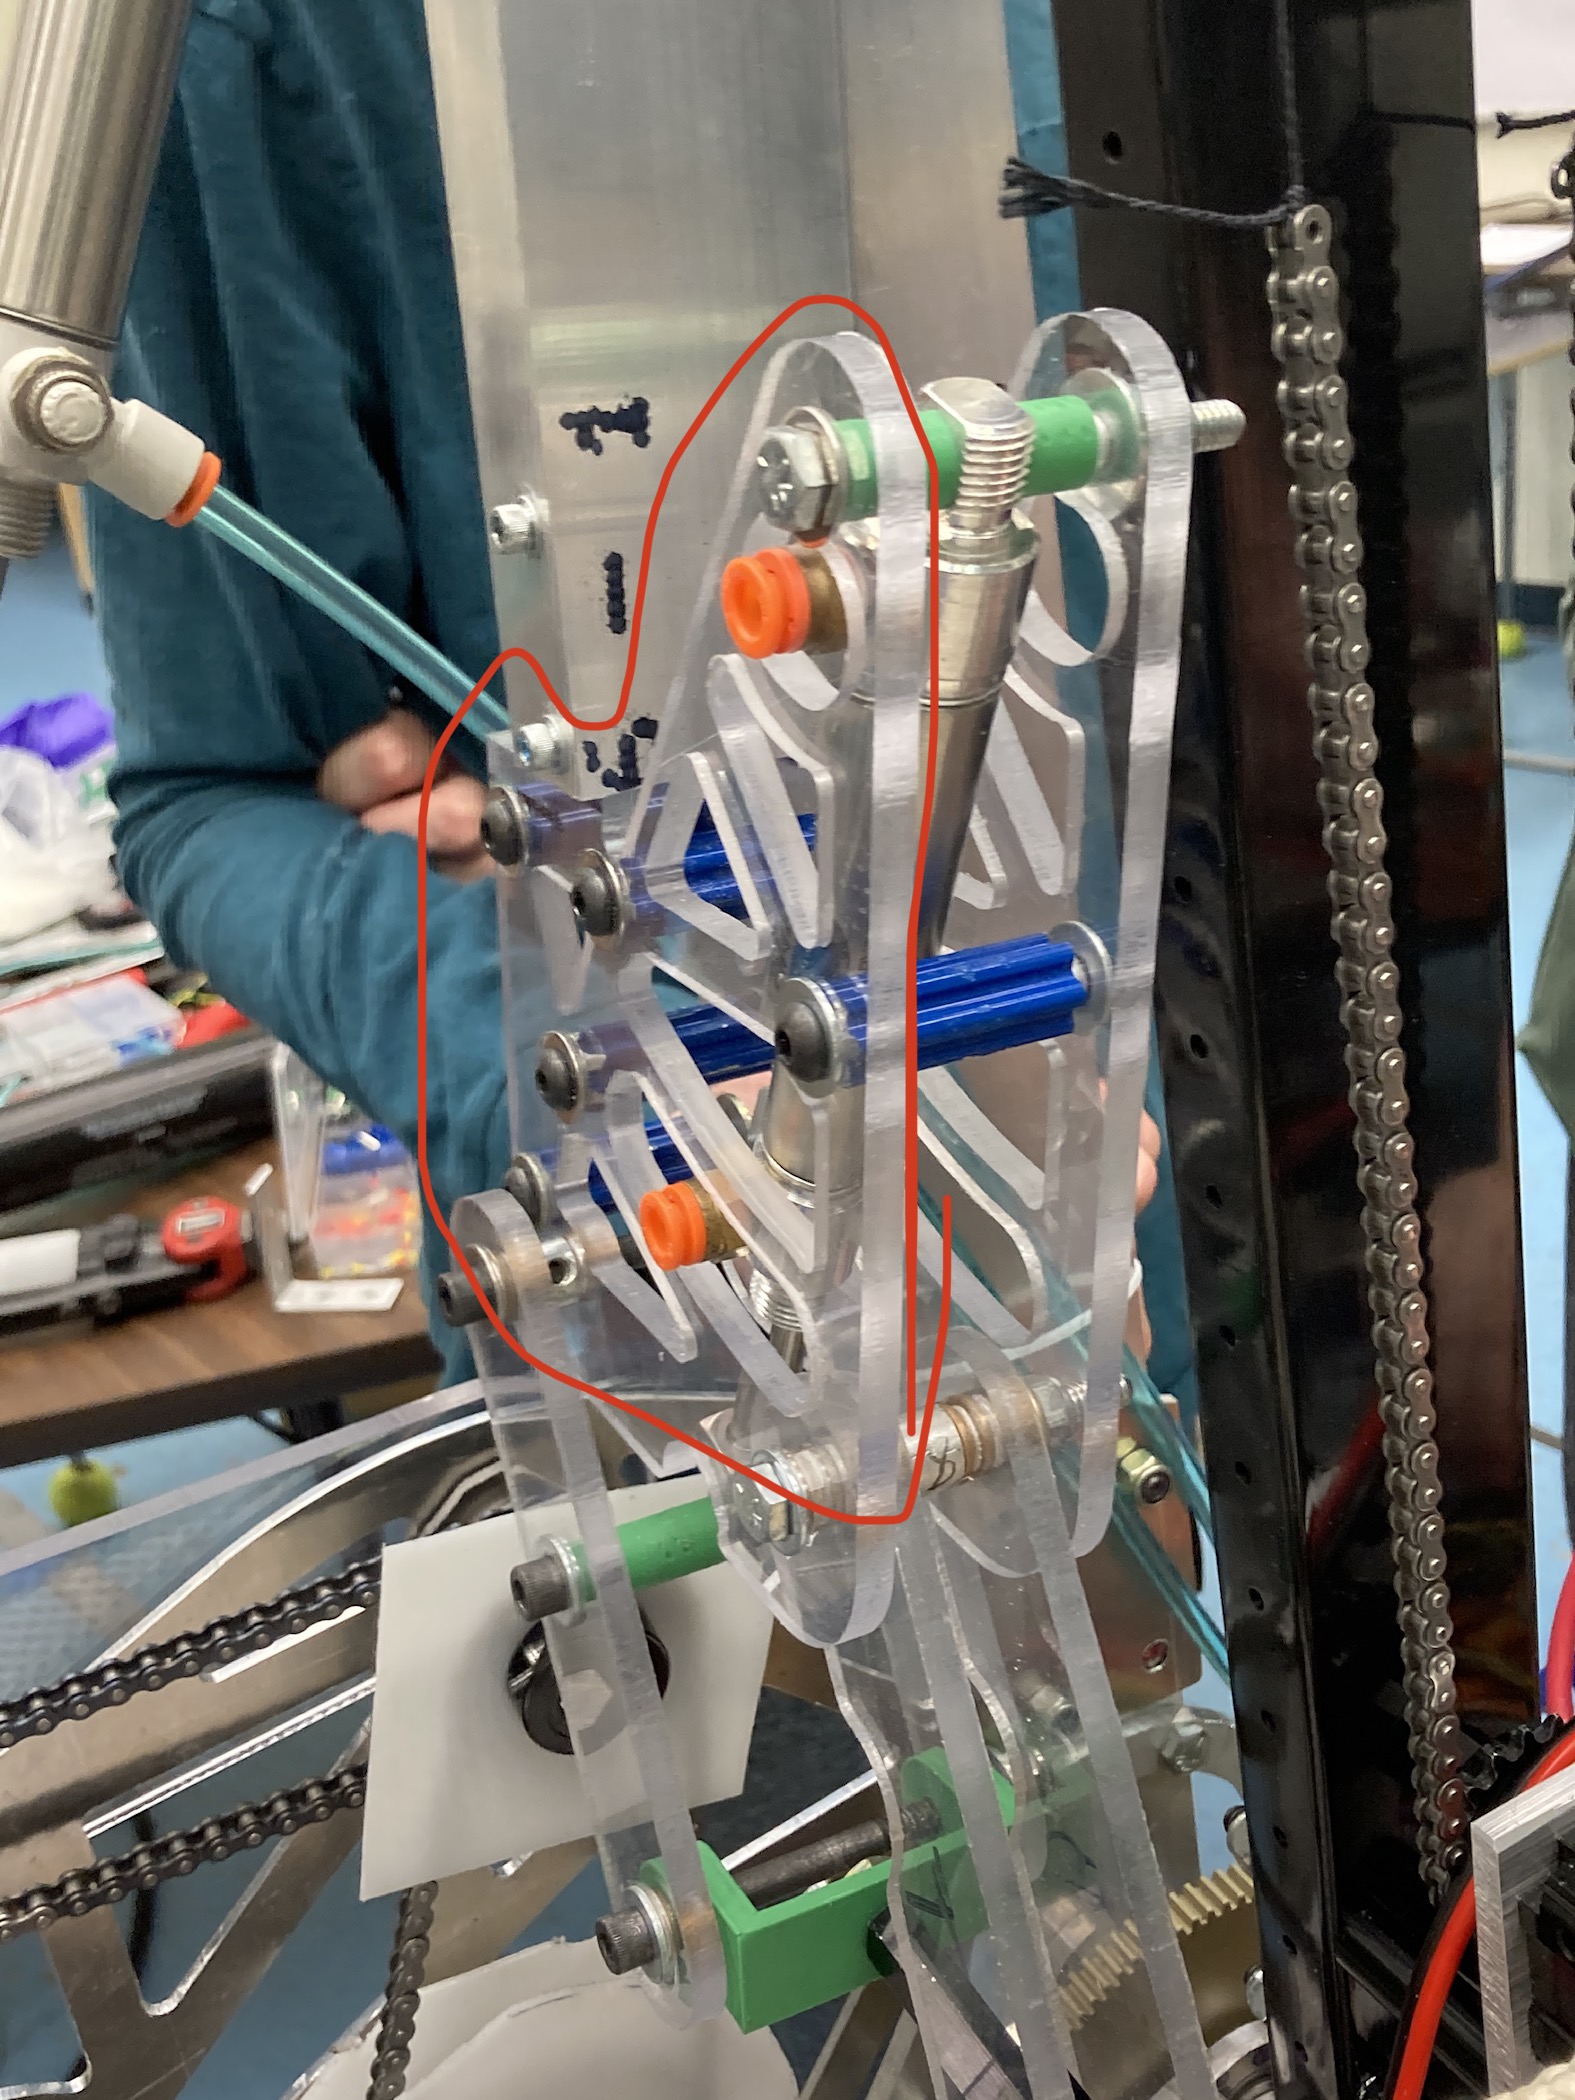
The first prototype opened like a cymbal monkey toy: each arm pivoted about
one axis, the two sides were synchronized by meshing gears, and pneumatic pistons
powered the motion.
It opened and closed as expected, but angular misalignment of the pads ruined
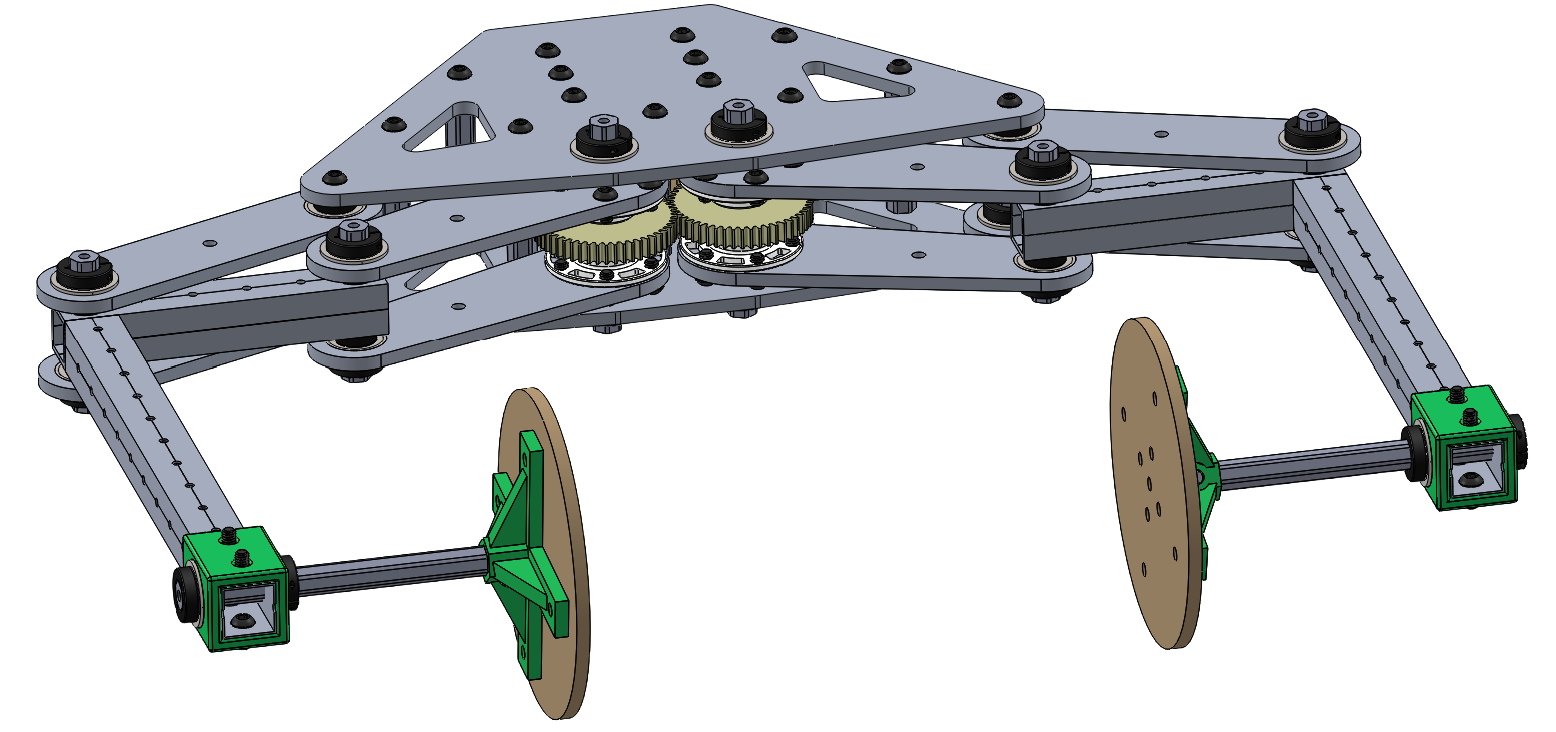
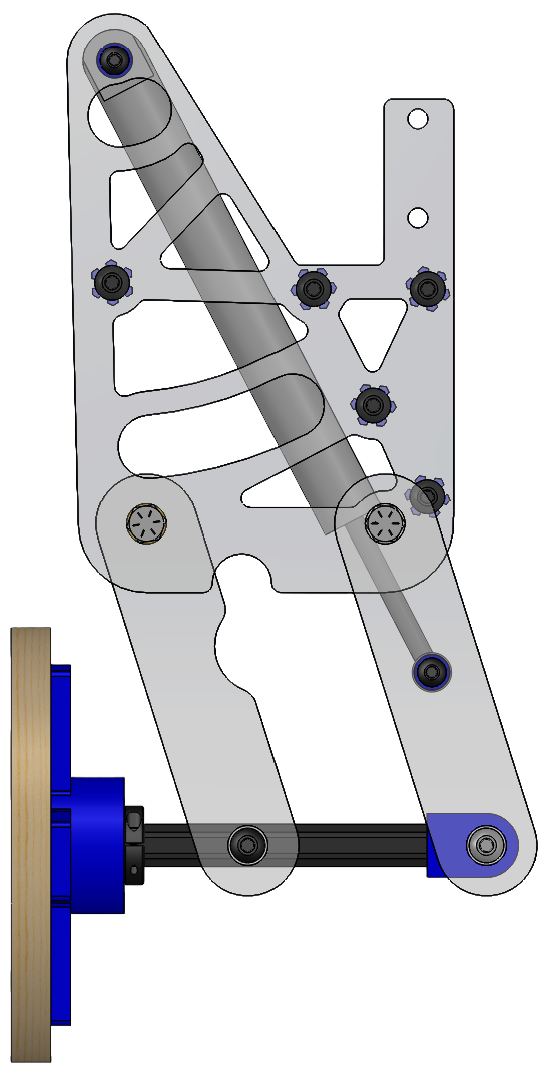
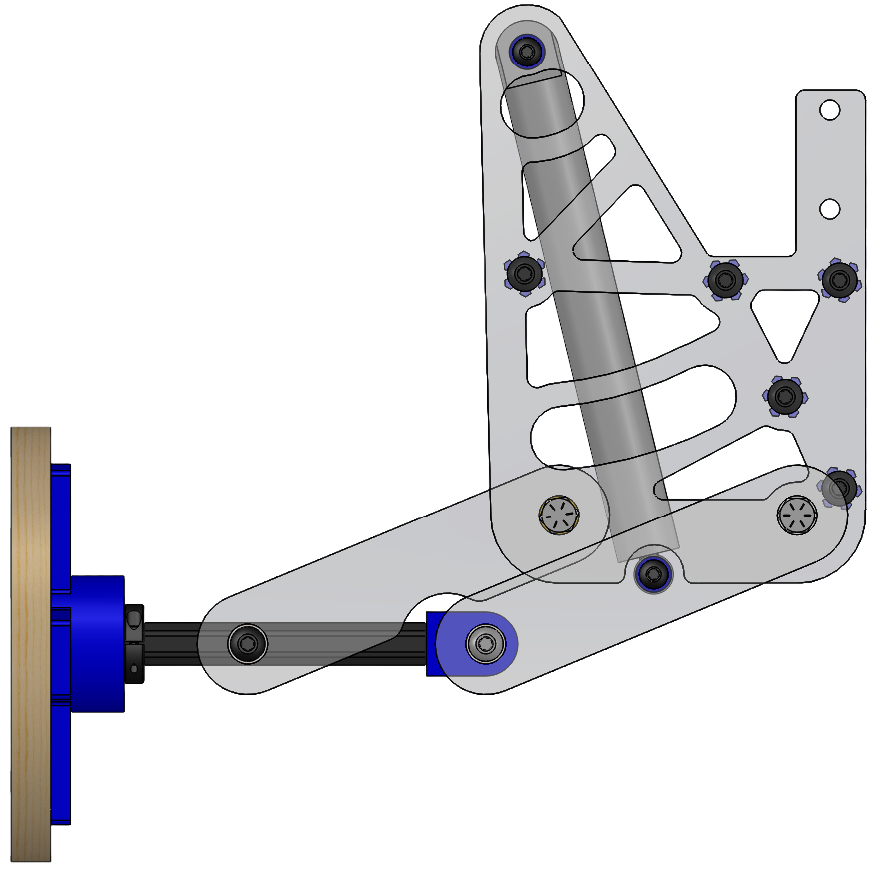
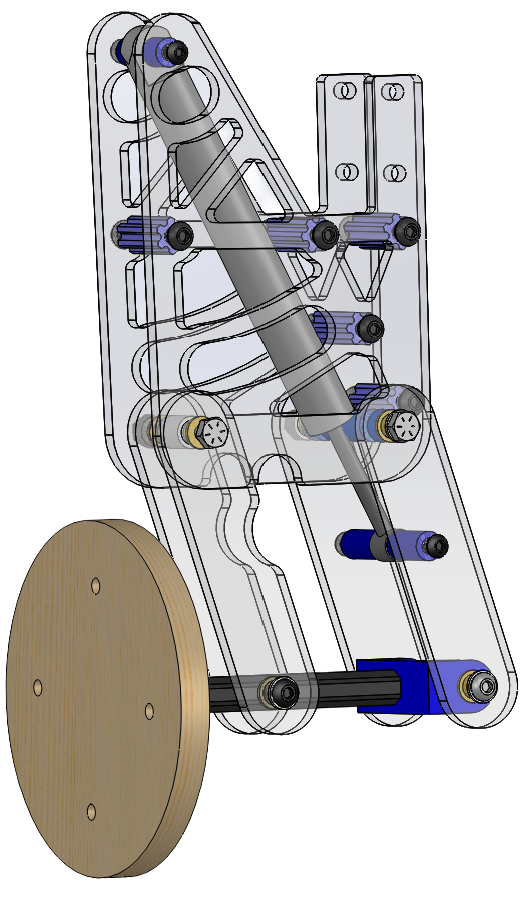
the gravity-rotation effect. That failure pushed the design toward four-bar
linkages to keep the contact surfaces aligned.